01
ARLO sees
- Perception & hazards
- Position & movement
- Sensor fusion
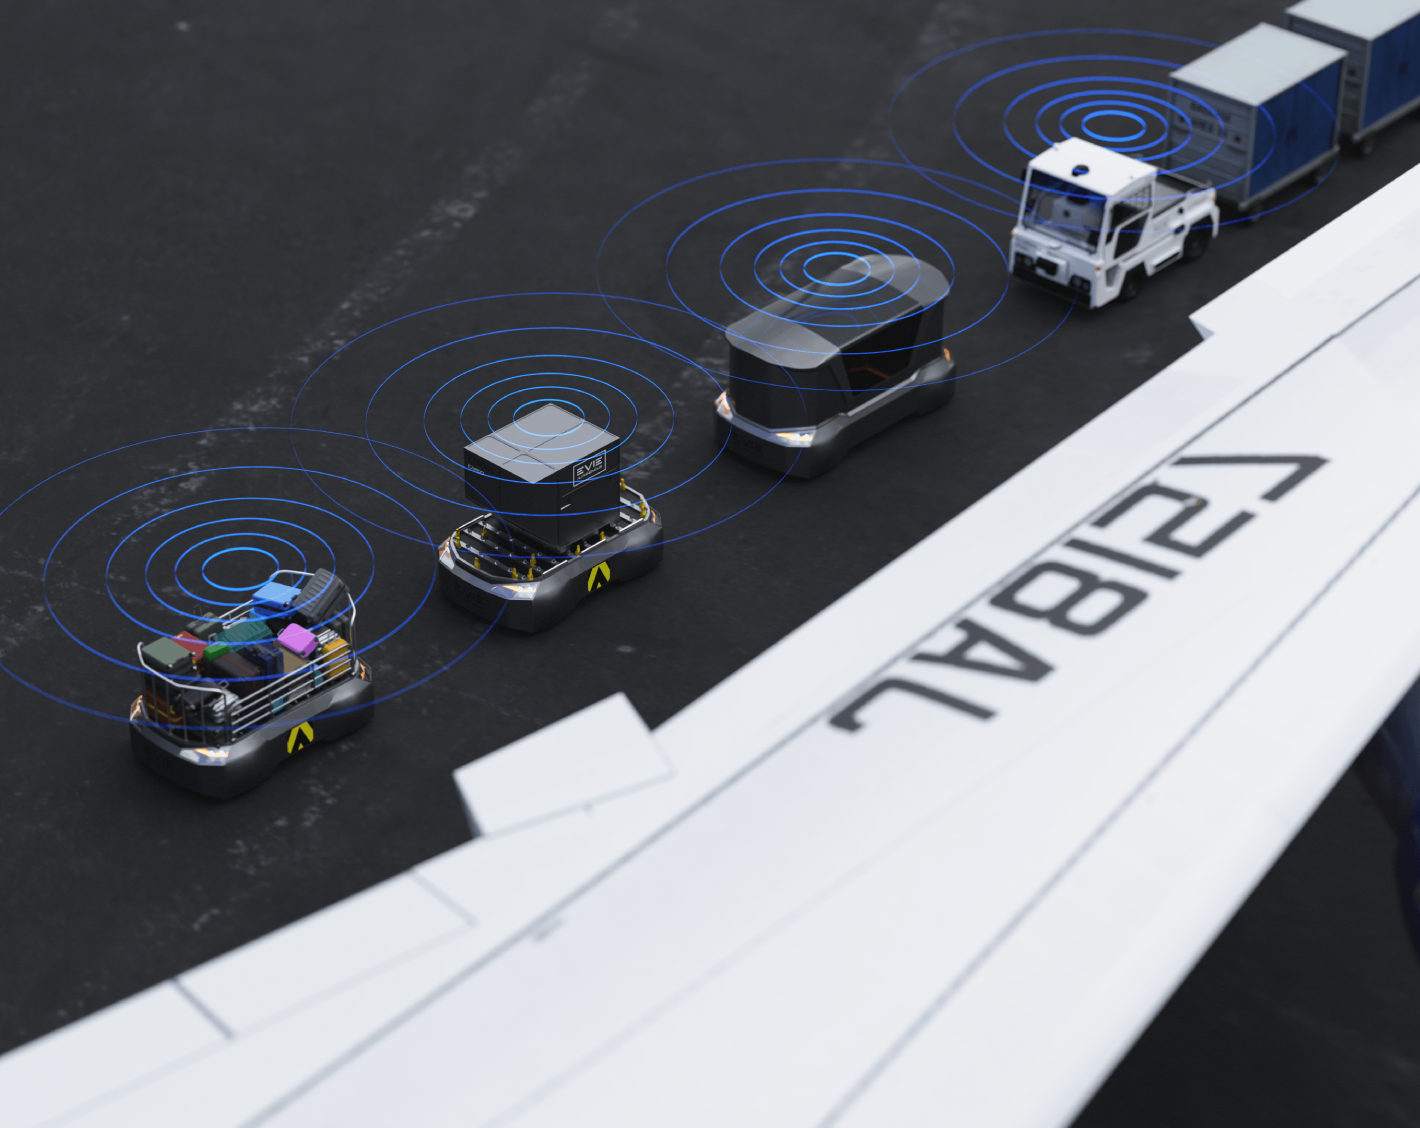
ARLO is our autonomy stack that brings together perception, artificial intelligence, real-time software, safety systems and machine integration to turn environmental information into controlled autonomous movement.
Explore the technologies that allow ARLO to see, understand, decide, act and operate safely across different vehicles, machines and environments.
01
02
03
04
Overview
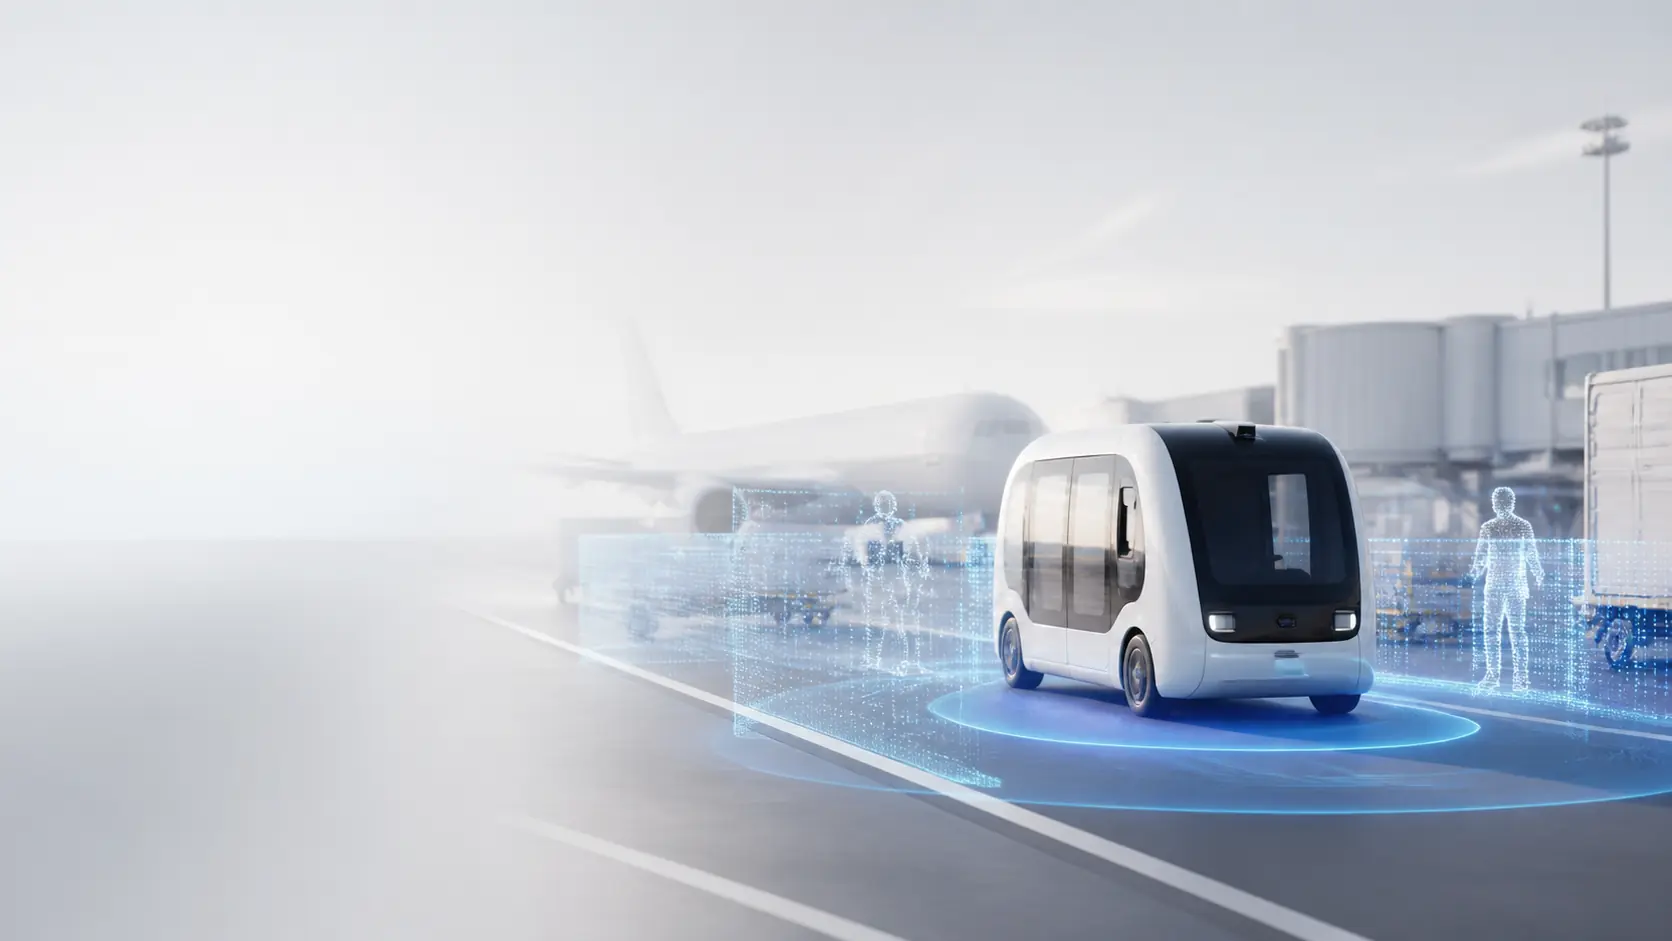
Before ARLO can decide what to do, it first needs to understand where it is and what is happening around it.
ARLO combines AI vision, AI-enhanced 4D radar, positioning and multiple sensing technologies to continuously build a picture of the operating environment.
Depending on the application, this can include detecting and tracking people, vehicles, machinery, infrastructure, route boundaries, obstacles, operating zones and unexpected hazards.
ARLO is not simply asking “Is something there?”
It is building the information needed to understand:
AI-enhanced 4D radar
4D radar provides ARLO with reliable perception in difficult operating conditions where cameras or LiDAR may be compromised.
ARLO uses radar for:
Identifying obstacles, people, vehicles and machinery, including blind-spot monitoring.
Understanding drivable areas and operating through rain, fog, dust, smoke and darkness.
Supporting odometry, SLAM and operation where satellite positioning is unreliable.
Measuring closing speed, movement and changes within the environment.
AI processing improves the radar output by classifying targets, removing noise and tracking objects consistently over time. ARLO can use successive observations to estimate trajectories and predict where an object is likely to move next.
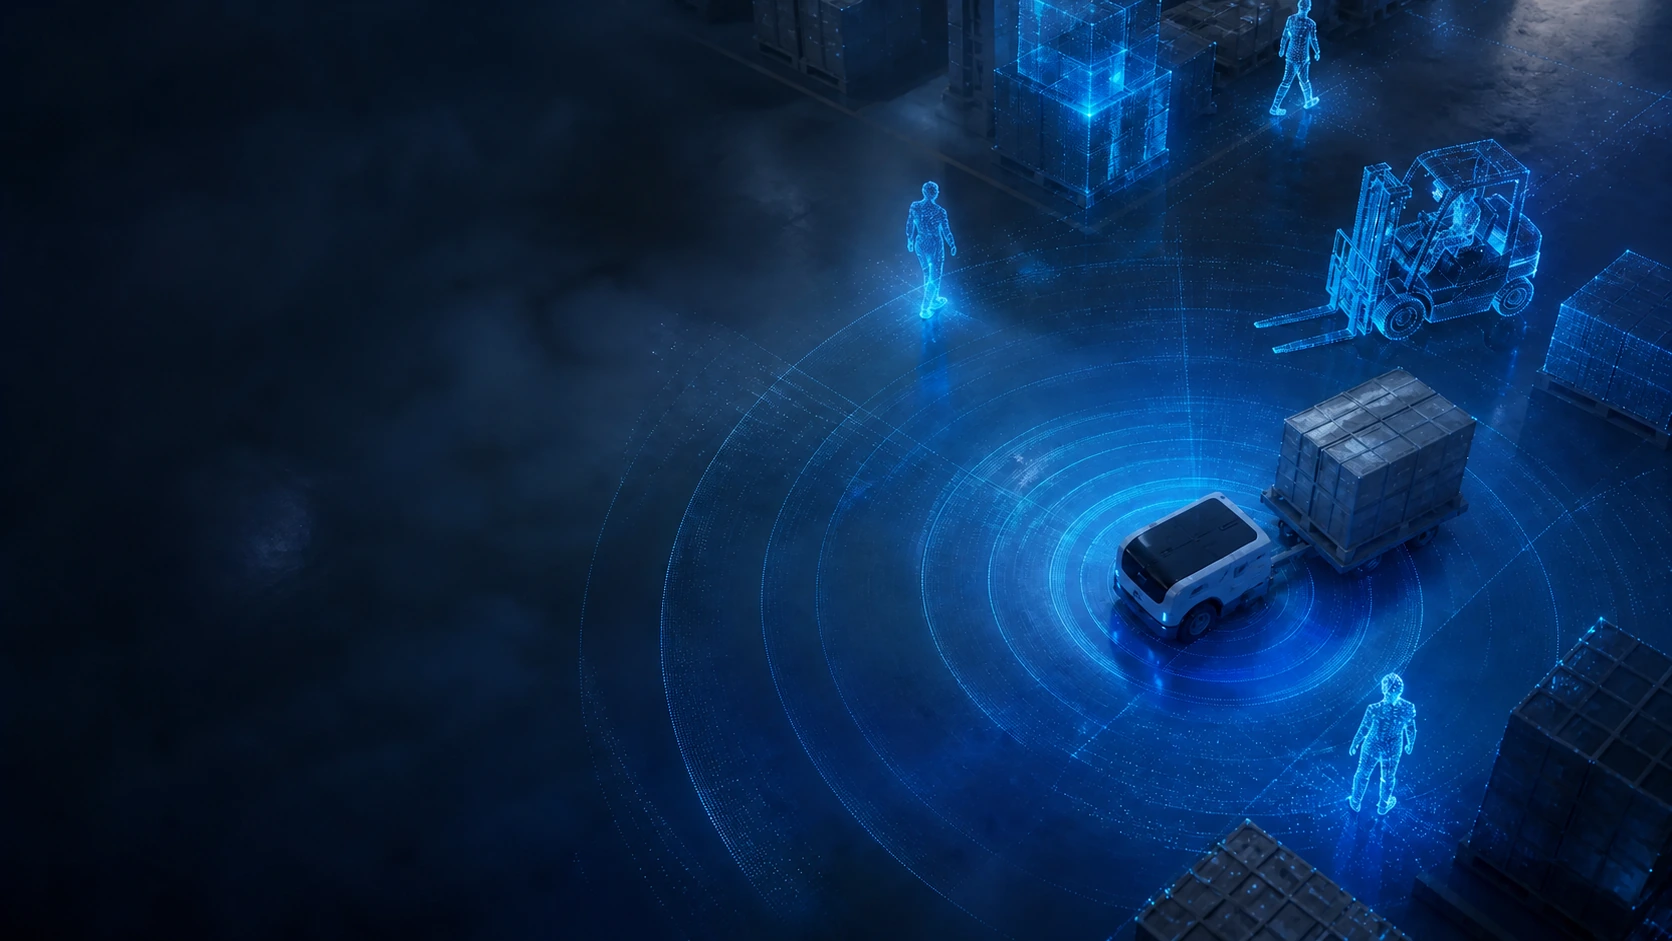
Radar provides information about:
Where an object is in 3D space.
AI vision
ARLO can use visible-light, low-light, thermal, stereo or specialist cameras depending on the application.
The image-processing AI runs on the vehicle, allowing ARLO to respond in real time without depending on a cloud connection.
EVIE can train and adapt AI models for the machine, working environment and operation required. The deployed models process information on the vehicle to support real-time decisions.
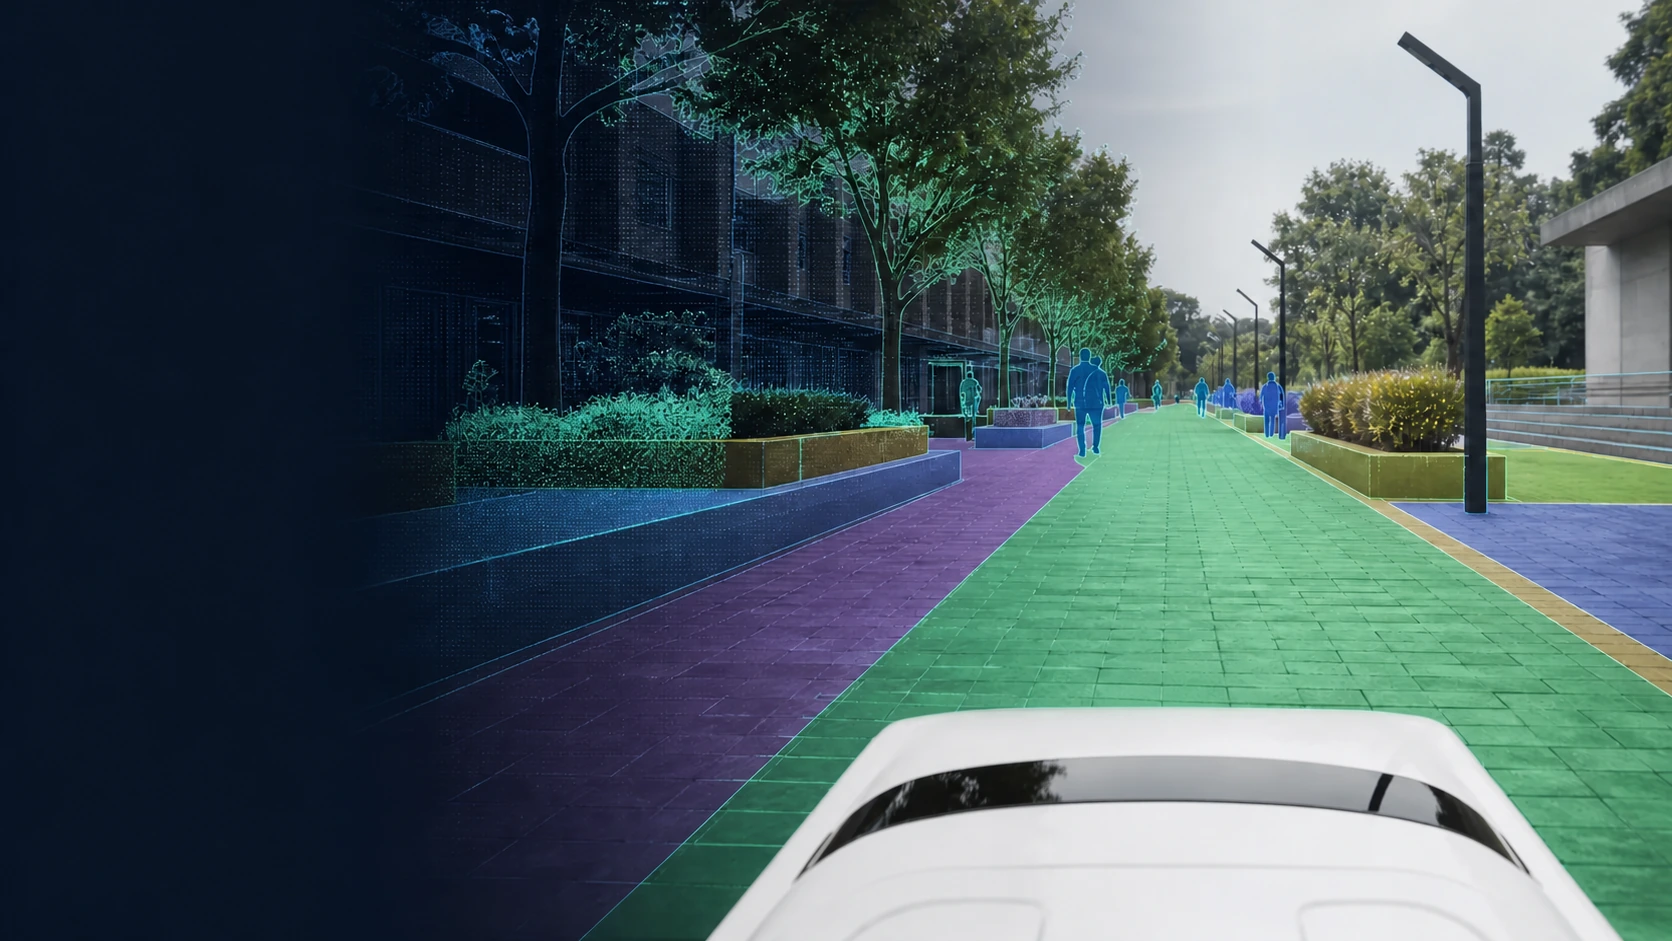
The camera system is used for:
Identifies and classifies people, vehicles, animals, obstacles, objects and materials.
Positioning
ARLO uses GNSS/GPS with RTK corrections to achieve centimetre-level positioning where suitable satellite visibility is available.
Correction data can be delivered through a cellular connection using NTRIP, including 5G where supported, or by radio depending on the installation.
It is used for:
Accurate positioning and route following across fields, airports, mines and industrial sites.
Inertial sensing and vehicle odometry
An IMU measures acceleration and rotation across multiple axes. It helps ARLO maintain an accurate understanding of movement between external position updates.
Wheel-speed, steering-angle and drivetrain information can also be incorporated to improve vehicle odometry.
It supports:
Heading, pitch, roll, yaw and overall vehicle-motion estimation.
SLAM and satellite-denied localisation
ARLO can construct a map while simultaneously determining its position within that map.
Depending on the environment, ARLO can combine radar and visual SLAM with inertial and wheel odometry, previously recorded maps, known landmarks and RTK positioning when available.
This allows ARLO to operate in warehouses, tunnels, mines, covered areas, beneath vegetation and other GNSS-denied or GNSS-degraded locations.
Subsurface sensing
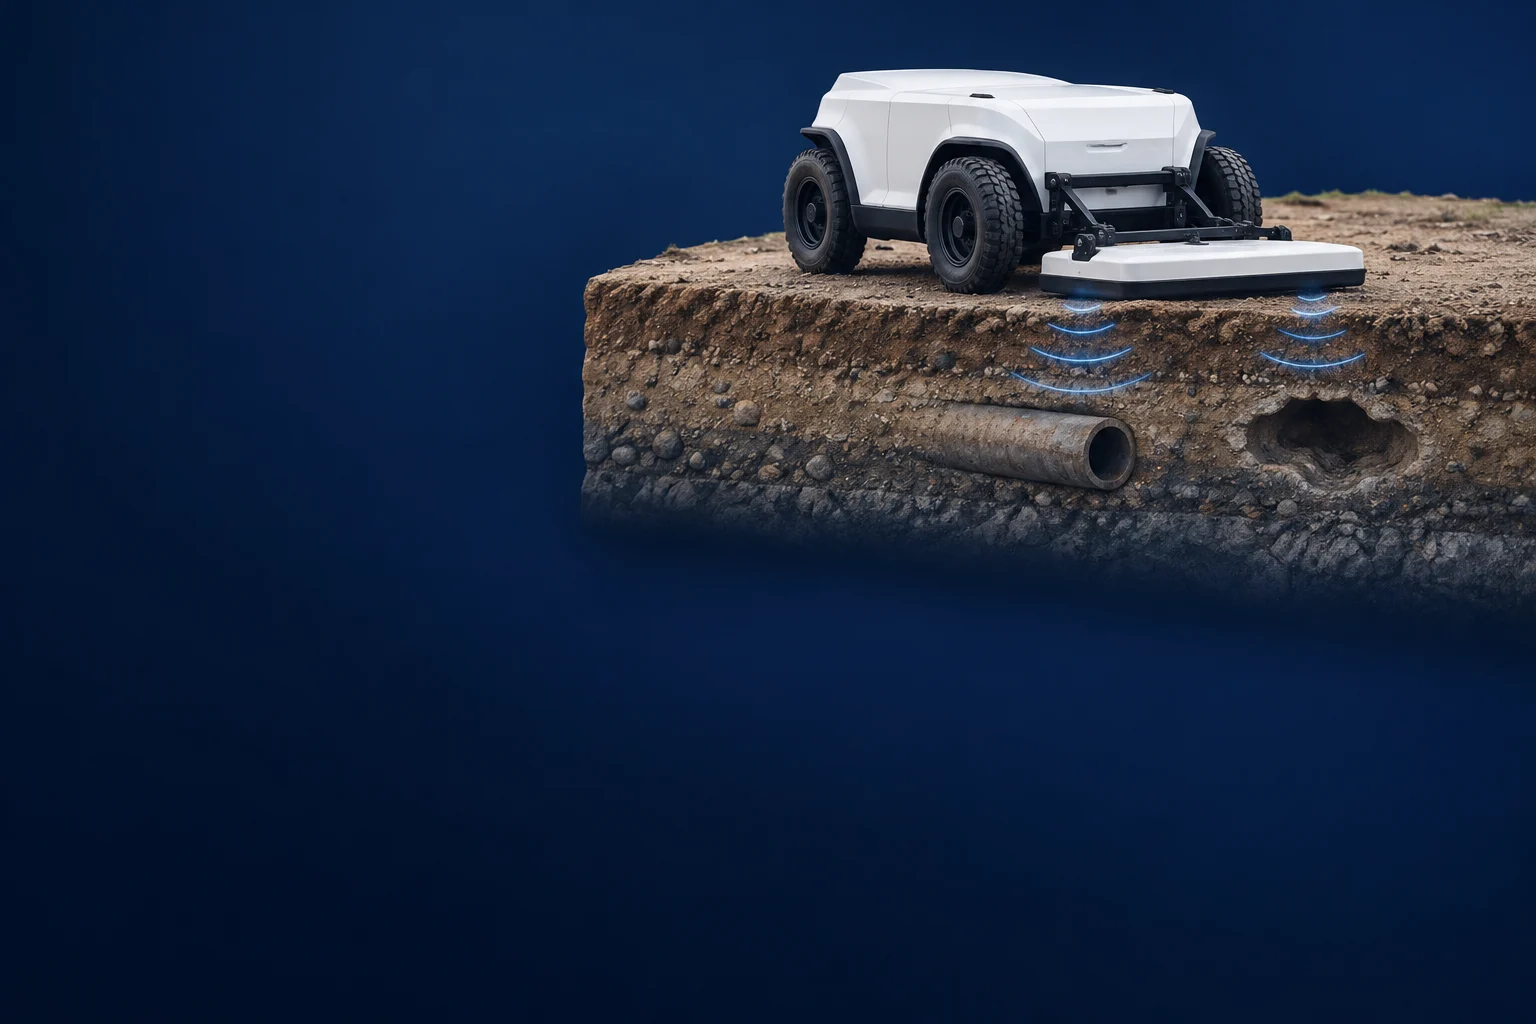
Ground-penetrating radar, or GPR, allows ARLO to detect and analyse features below the surface.
Real-time edge AI can analyse GPR data to identify patterns and anomalies, then combine the results with surface imagery, vehicle position and other sensor data.
GPR is primarily used for subsurface sensing, but in specialist applications it can also support localisation alongside inertial, radar, visual and wheel-based positioning.
It can support:
Including landmines, unexploded ordnance and underground utilities.
Sensor fusion
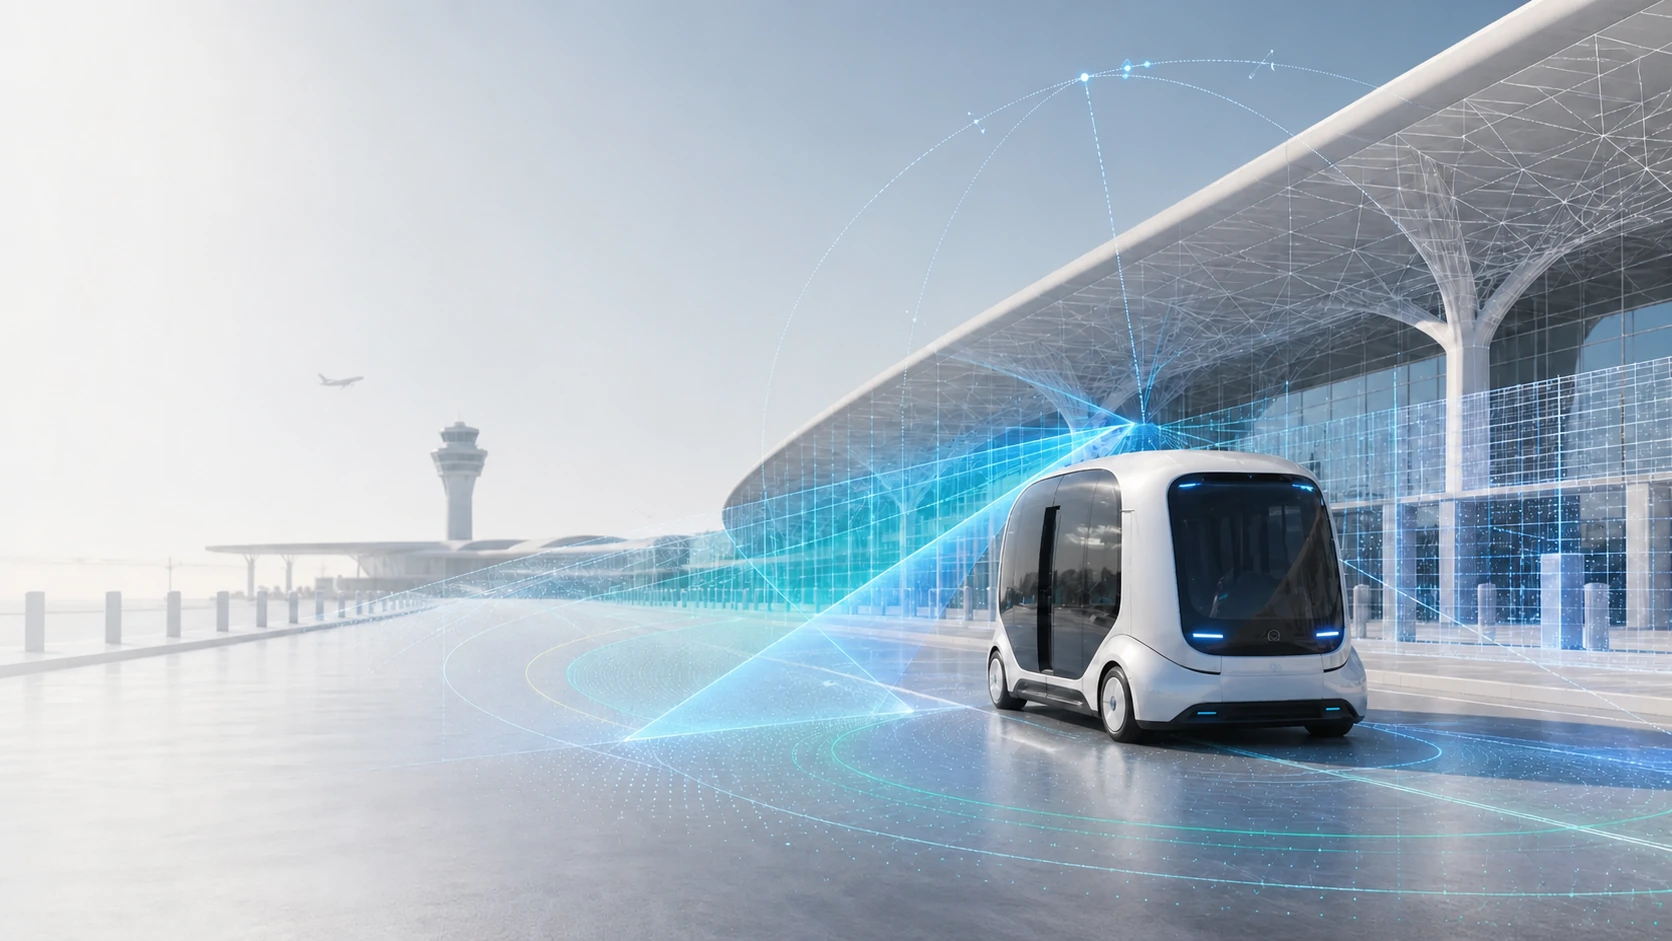
ARLO combines radar, cameras, positioning, inertial sensing and machine feedback into one continuously updated view of the environment.
Different sensors complement each other, helping ARLO maintain reliable perception across changing conditions.
Position, classification, direction, velocity and predicted movement.
Overview
Before ARLO can decide what to do, it first needs to understand where it is and what is happening around it.
ARLO combines AI vision, AI-enhanced 4D radar, positioning and multiple sensing technologies to continuously build a picture of the operating environment.
Depending on the application, this can include detecting and tracking people, vehicles, machinery, infrastructure, route boundaries, obstacles, operating zones and unexpected hazards.
ARLO is not simply asking “Is something there?”
It is building the information needed to understand:
AI-enhanced 4D radar
4D radar provides ARLO with reliable perception in difficult operating conditions where cameras or LiDAR may be compromised.
ARLO uses radar for:
Identifying obstacles, people, vehicles and machinery, including blind-spot monitoring.
Understanding drivable areas and operating through rain, fog, dust, smoke and darkness.
Supporting odometry, SLAM and operation where satellite positioning is unreliable.
Measuring closing speed, movement and changes within the environment.
AI processing improves the radar output by classifying targets, removing noise and tracking objects consistently over time. ARLO can use successive observations to estimate trajectories and predict where an object is likely to move next.
Radar provides information about:
Where an object is in 3D space.
How fast it is moving and how that movement is changing.
Information that helps distinguish surfaces and object types.
AI vision
ARLO can use visible-light, low-light, thermal, stereo or specialist cameras depending on the application.
The image-processing AI runs on the vehicle, allowing ARLO to respond in real time without depending on a cloud connection.
EVIE can train and adapt AI models for the machine, working environment and operation required. The deployed models process information on the vehicle to support real-time decisions.
The camera system is used for:
Identifies and classifies people, vehicles, animals, obstacles, objects and materials.
Breaks the scene into meaningful areas such as roads, crop rows, boundaries, infrastructure and traversable space.
Follows detected objects across successive frames to understand movement, direction and changing positions.
Uses visual information to assess whether an area is safe, accessible or relevant to the task.
Interprets crops, equipment, road surfaces, working areas, indicators, labels and machine states.
Positioning
ARLO uses GNSS/GPS with RTK corrections to achieve centimetre-level positioning where suitable satellite visibility is available.
Correction data can be delivered through a cellular connection using NTRIP, including 5G where supported, or by radio depending on the installation.
It is used for:
Accurate positioning and route following across fields, airports, mines and industrial sites.
Return to the same working, charging, loading or service locations with consistent accuracy.
Use geofencing, direction-of-travel awareness and defined boundaries to control where the machine can operate.
Track completed work and coordinate multiple machines across the wider operation.
Inertial sensing and vehicle odometry
An IMU measures acceleration and rotation across multiple axes. It helps ARLO maintain an accurate understanding of movement between external position updates.
Wheel-speed, steering-angle and drivetrain information can also be incorporated to improve vehicle odometry.
It supports:
Heading, pitch, roll, yaw and overall vehicle-motion estimation.
Short-term dead reckoning and maintaining movement awareness through brief GNSS interruptions.
Accounting for vibration, uneven terrain and conditions that may affect stability or rollover risk.
SLAM and satellite-denied localisation
ARLO can construct a map while simultaneously determining its position within that map.
Depending on the environment, ARLO can combine radar and visual SLAM with inertial and wheel odometry, previously recorded maps, known landmarks and RTK positioning when available.
This allows ARLO to operate in warehouses, tunnels, mines, covered areas, beneath vegetation and other GNSS-denied or GNSS-degraded locations.
Subsurface sensing
Ground-penetrating radar, or GPR, allows ARLO to detect and analyse features below the surface.
Real-time edge AI can analyse GPR data to identify patterns and anomalies, then combine the results with surface imagery, vehicle position and other sensor data.
GPR is primarily used for subsurface sensing, but in specialist applications it can also support localisation alongside inertial, radar, visual and wheel-based positioning.
It can support:
Including landmines, unexploded ordnance and underground utilities.
Identifying soil layers, voids, moisture and disturbed ground.
Comparing current conditions with previously surveyed areas.
Using mapped underground features alongside other positioning systems.
Sensor fusion
ARLO combines radar, cameras, positioning, inertial sensing and machine feedback into one continuously updated view of the environment.
Different sensors complement each other, helping ARLO maintain reliable perception across changing conditions.
Position, classification, direction, velocity and predicted movement.
Location, orientation and operating state.
Drivable and workable areas.
Hazards and confidence in significant observations.
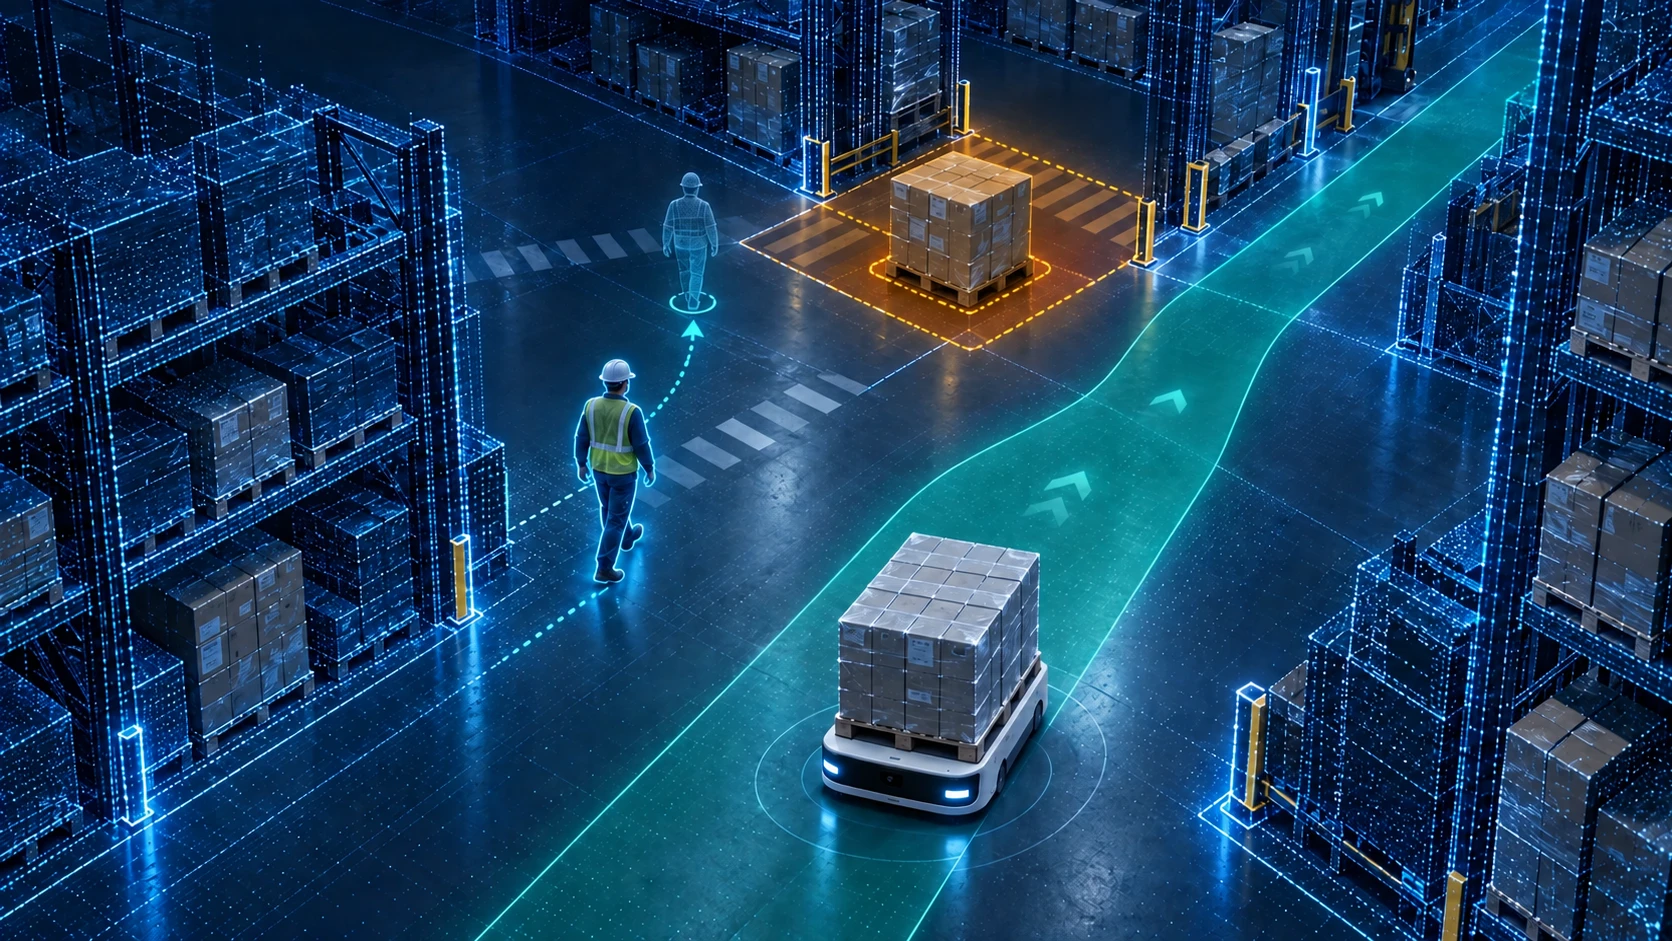
ARLO doesn’t just detect the world.
It builds an understanding of it.
Overview
Everything ARLO sees becomes information that can be processed. ARLO continuously has to answer the questions at the heart of autonomous operation:
From those answers ARLO can determine route, direction, speed, stopping position, obstacle avoidance, junction behaviour and mission progression.
“Different missions need different behaviours”
Building a live understanding
ARLO combines all perception and localisation information into a live digital representation of the machine’s surroundings.
The world model is continuously updated as the vehicle moves and conditions change.
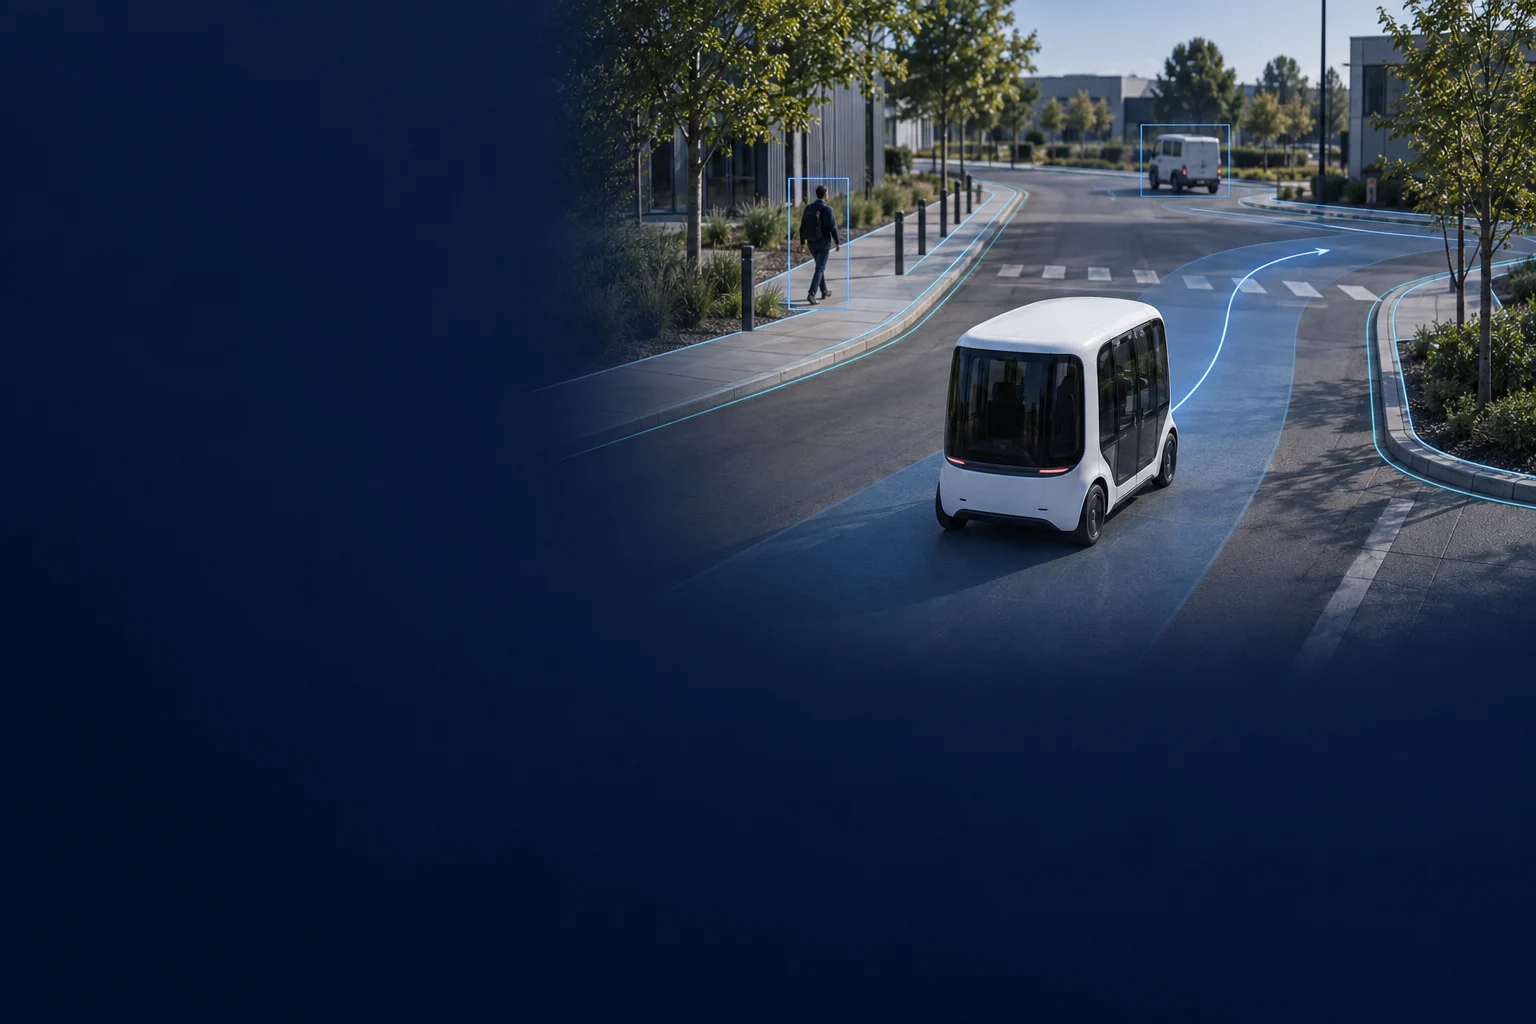
This world model contains:
Its position, direction and operating state.
Autonomous control
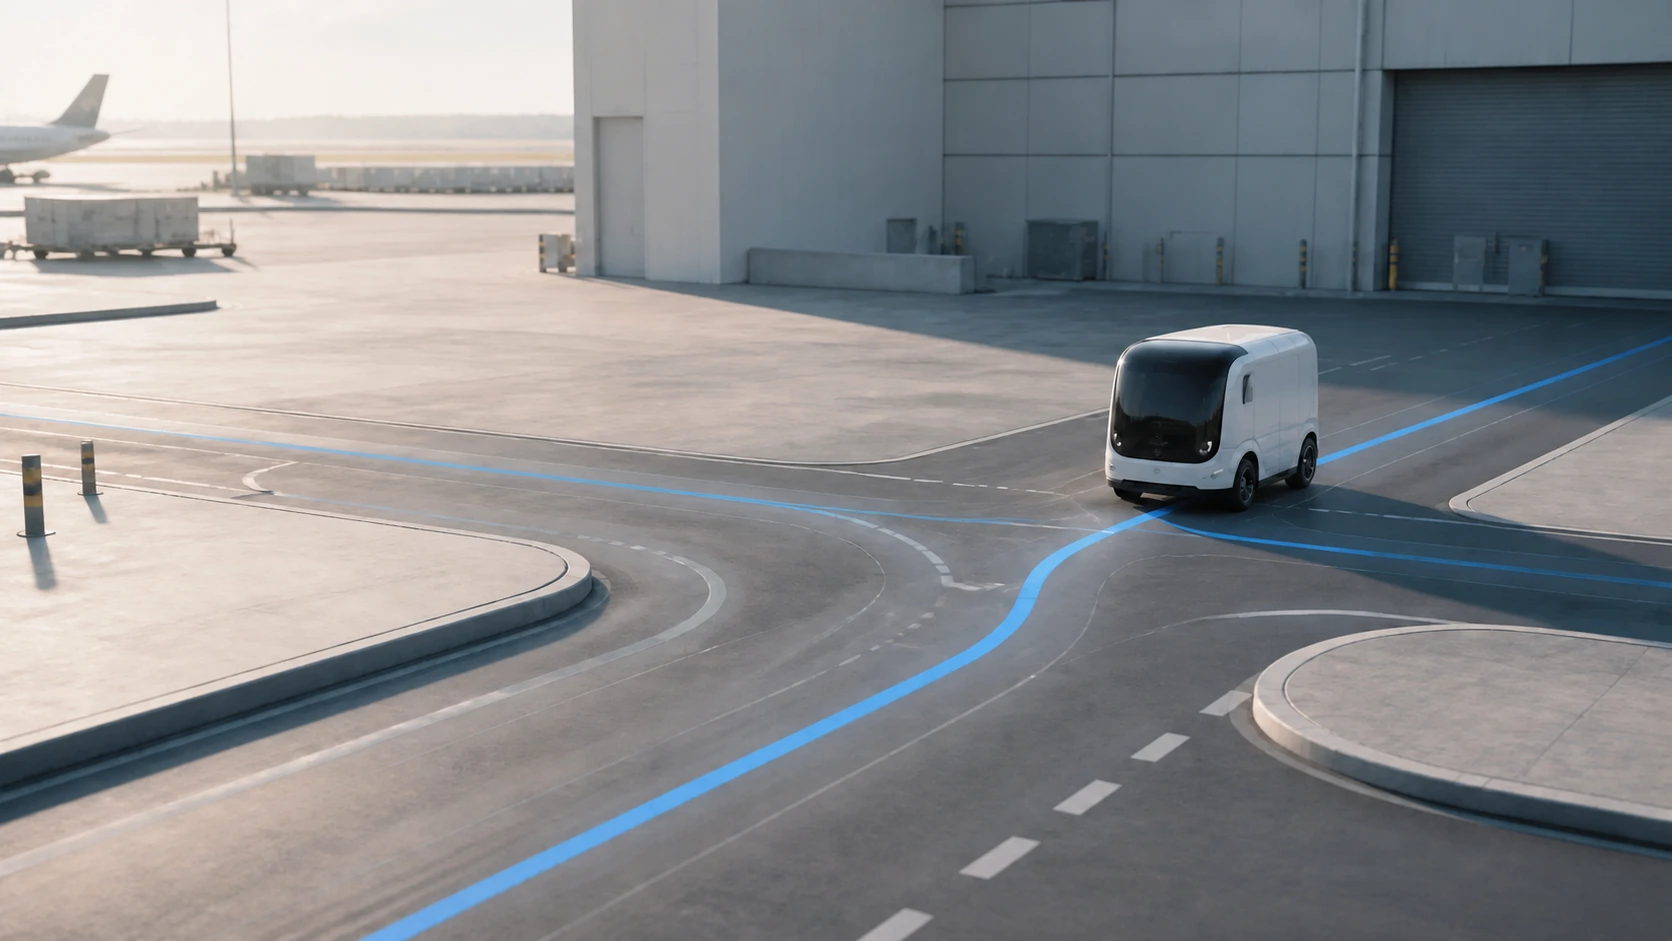
ARLO uses localisation, mapped route data and decision-making logic to determine how the machine should move through its environment.
It sits between ARLO’s understanding of the world and the mission-specific software that defines where and how the machine operates.
Mission and task management
ARLO is given an operation to complete rather than only a route to follow.
Missions can range from moving baggage or materials and inspecting sites, to selective spraying, perimeter patrol, vegetation clearance and surveying for buried hazards.
The mission-management layer breaks this objective into individual actions, monitors progress and responds to changes.
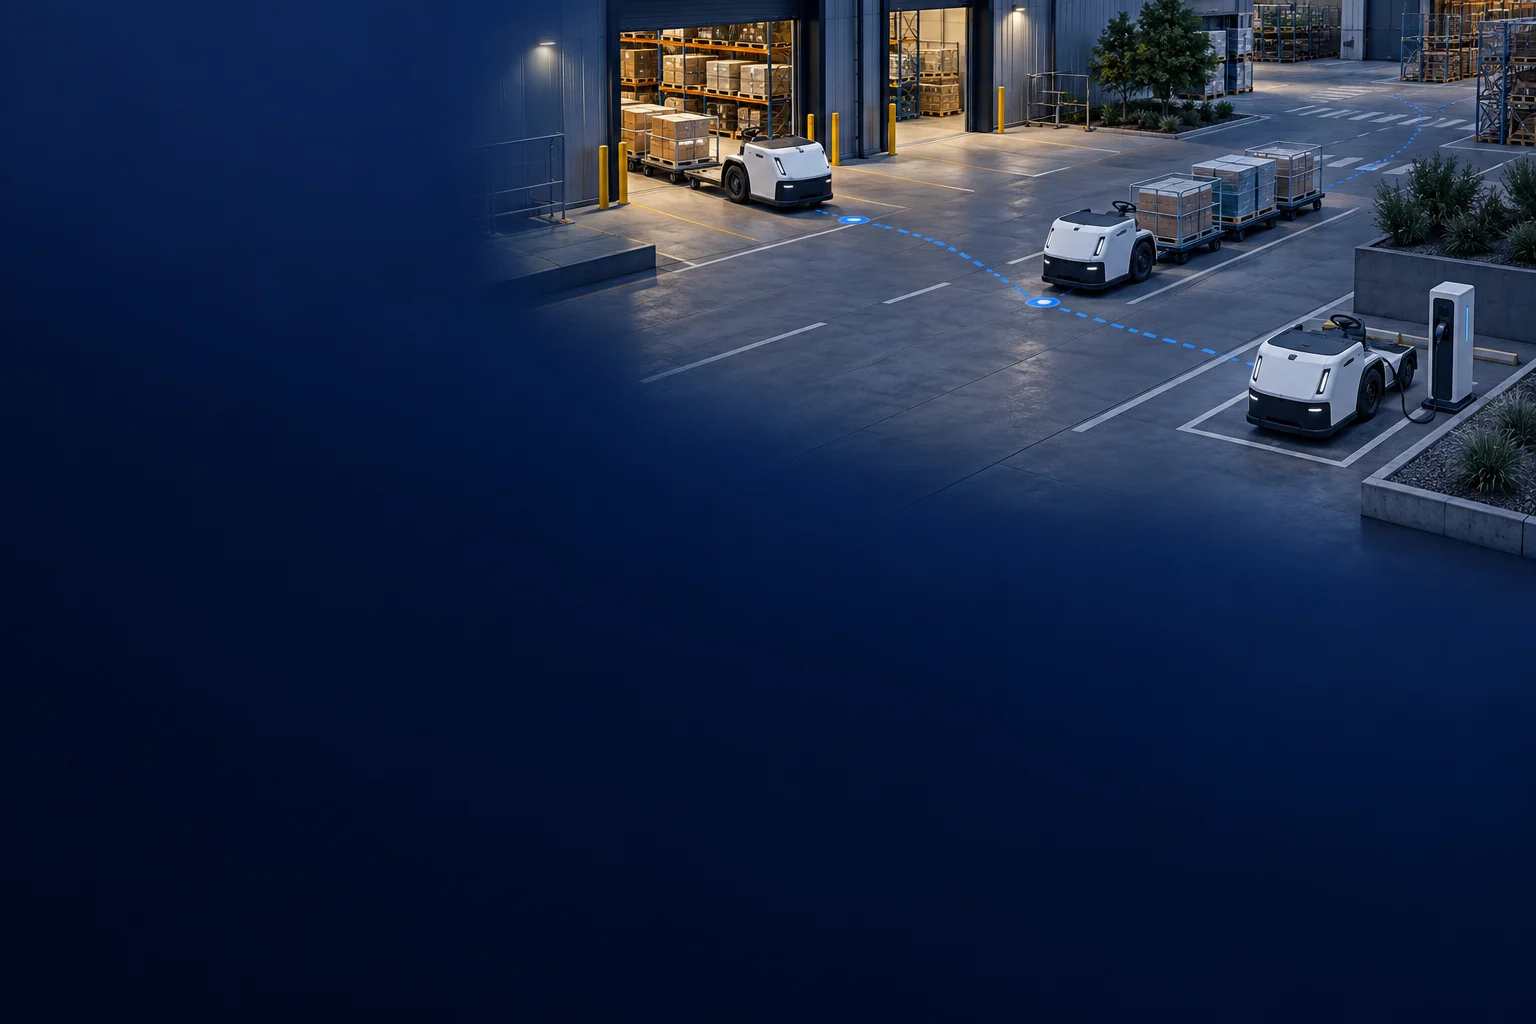
It can manage:
Sequencing actions, allocating work areas and planning route or coverage.
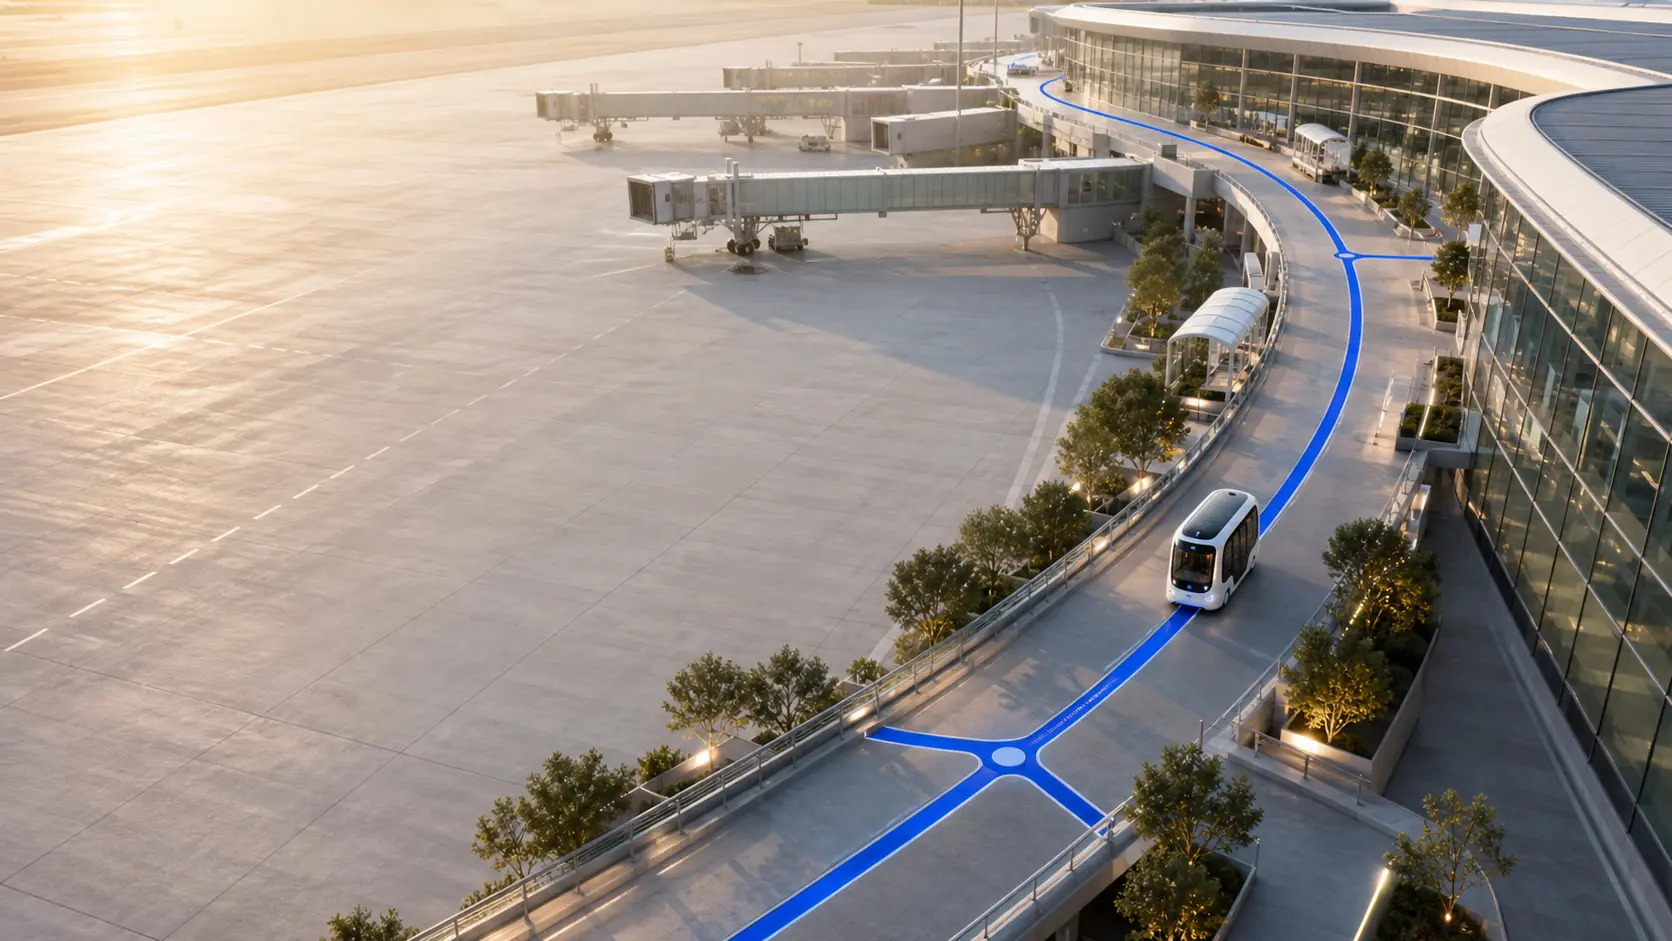
Defined route autonomy
ARLO supports applications where a machine follows a defined circular route repeatedly.
The current technology was developed for applications such as airport transportation and can incorporate junctions, stops and repeatable operating paths.
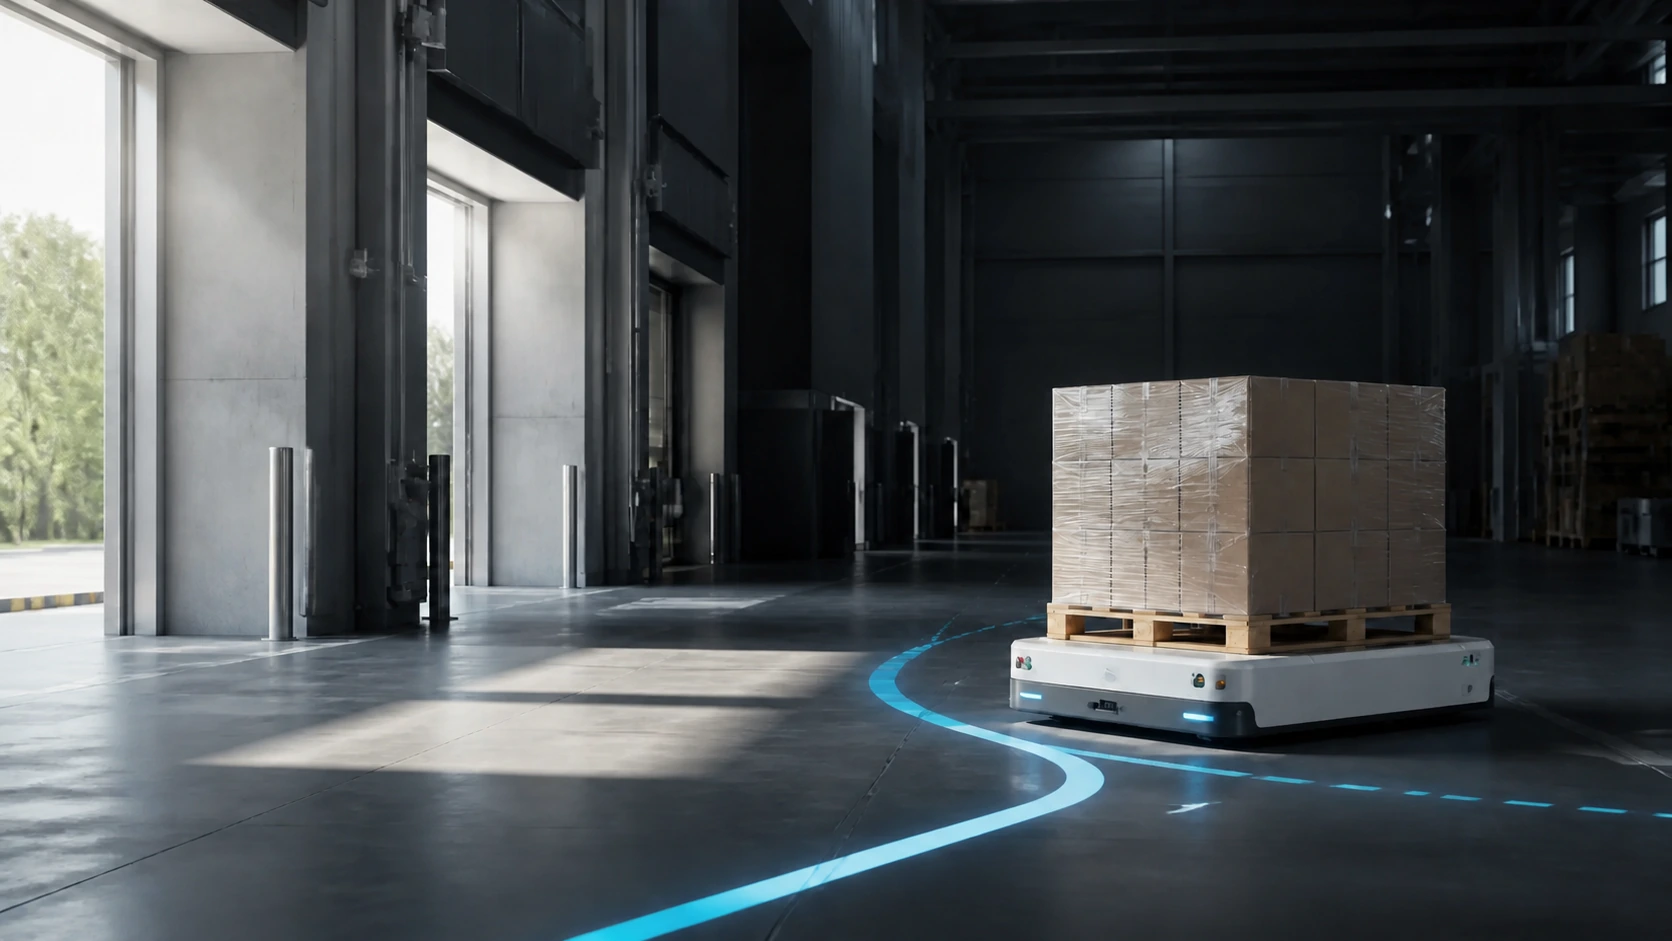
Direct route autonomy
ARLO can be configured for movement between defined locations rather than a continuous loop.
That makes it suitable for operations where machines repeatedly move between operational points, such as material handling or depot movements.
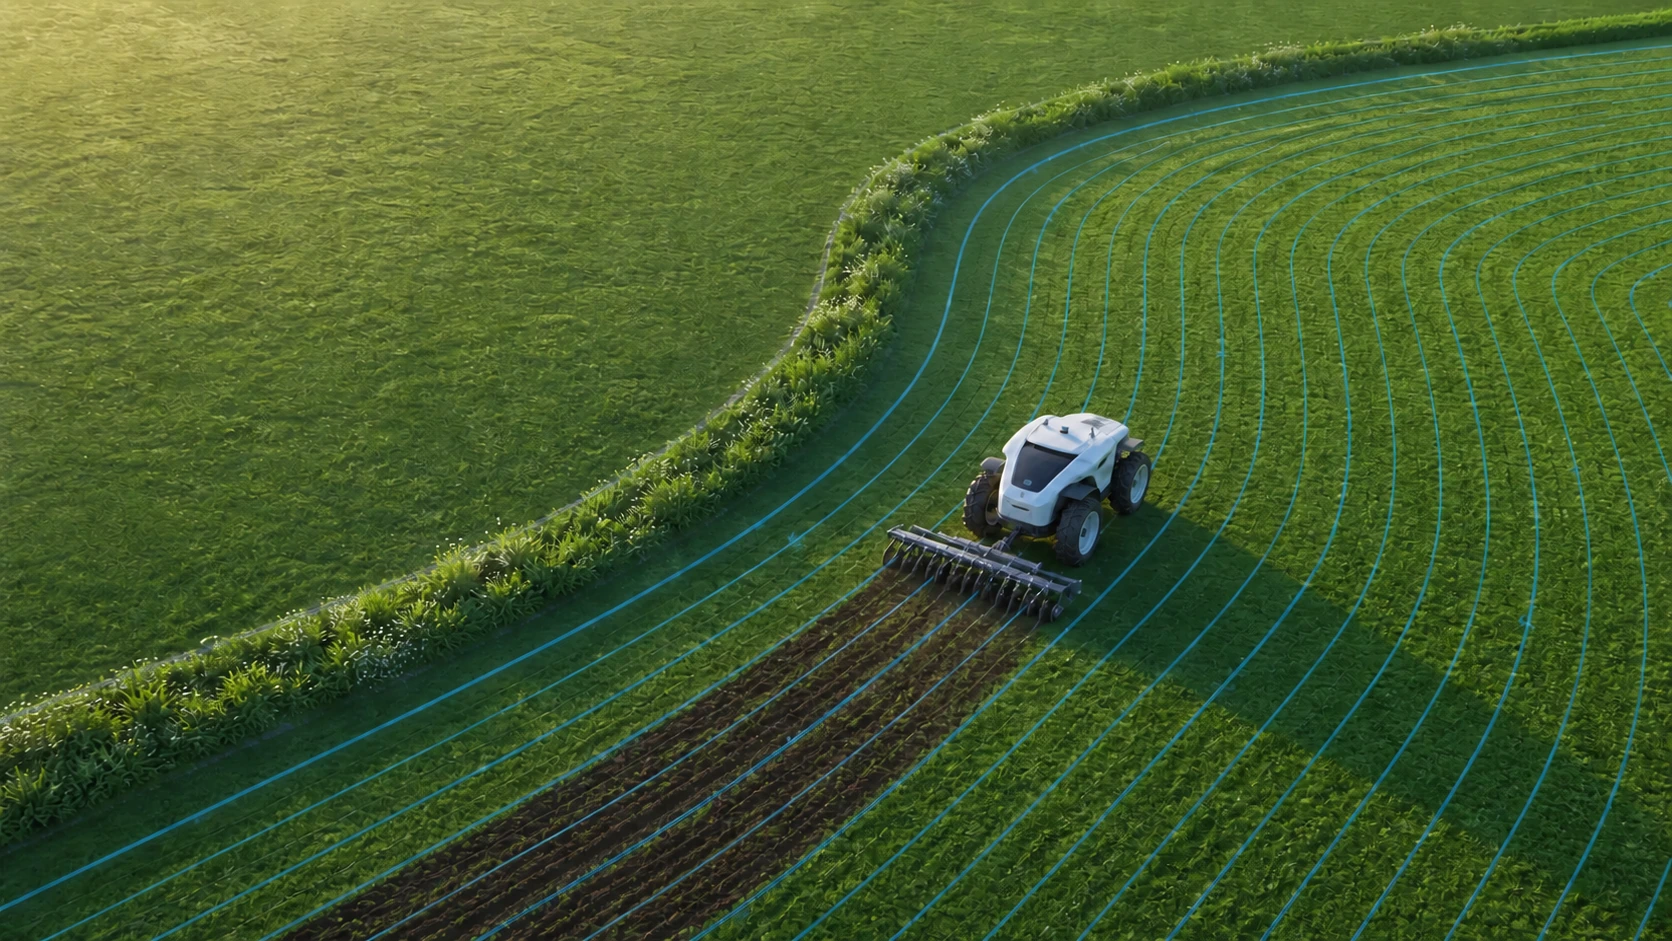
Agricultural autonomy
ARLO can be configured specifically for agricultural applications.
He can generate an efficient route across a field after its perimeter is defined, supporting autonomous operations such as ploughing, mowing, seeding and spraying.
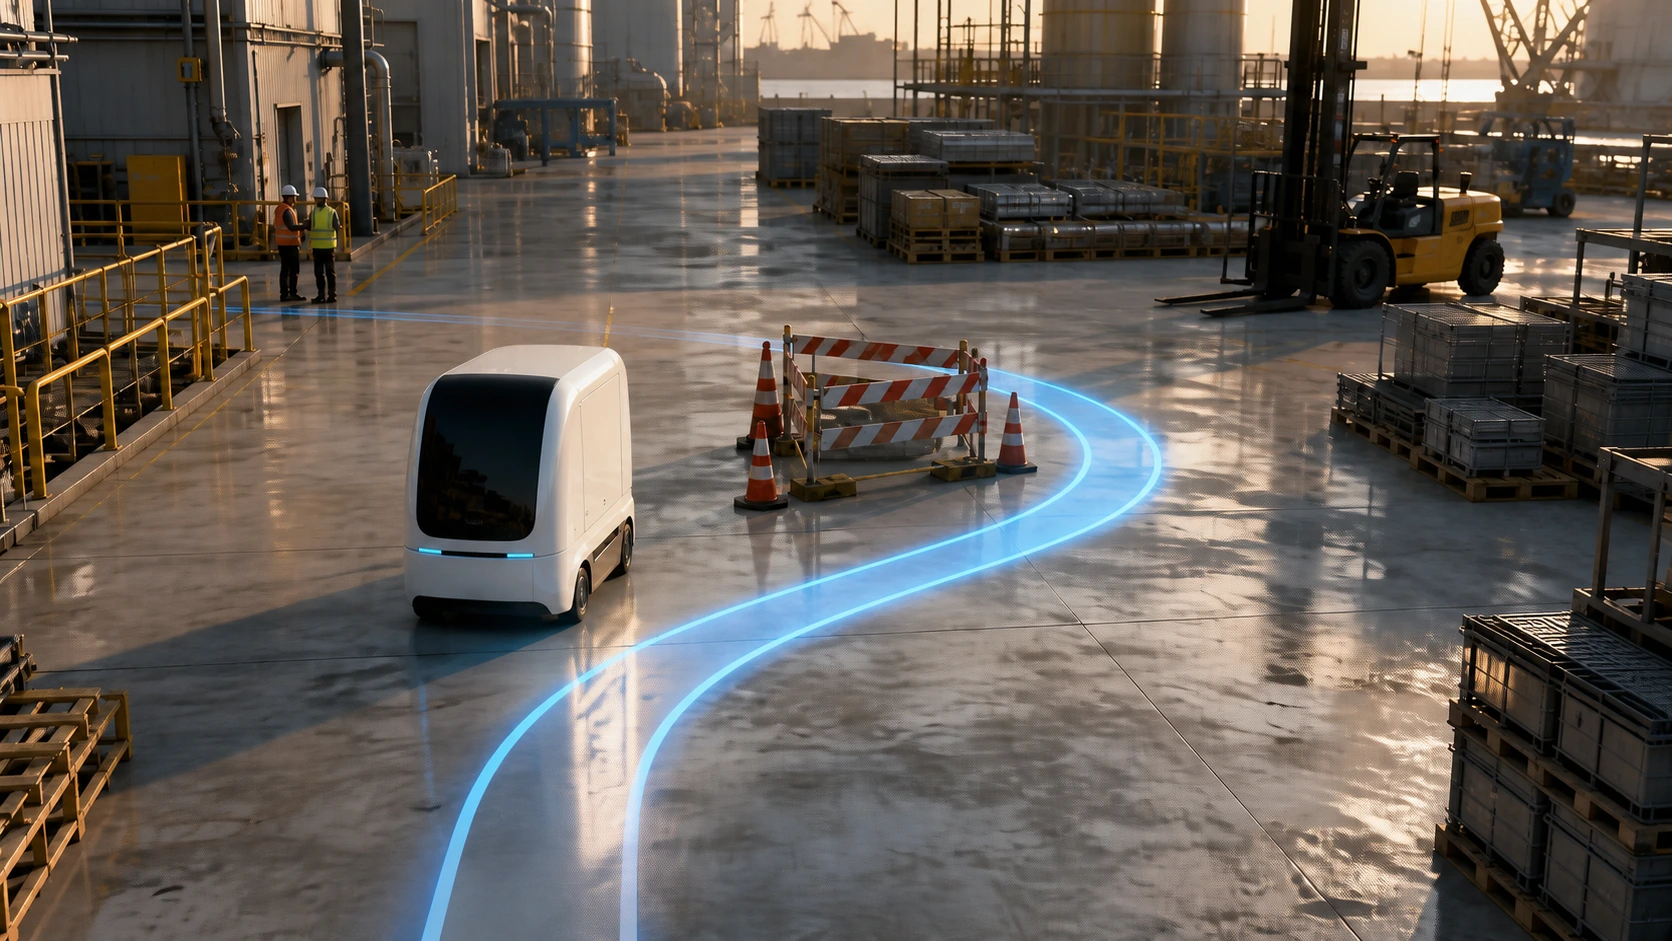
Collision avoidance
Perception only creates value when it changes behaviour.
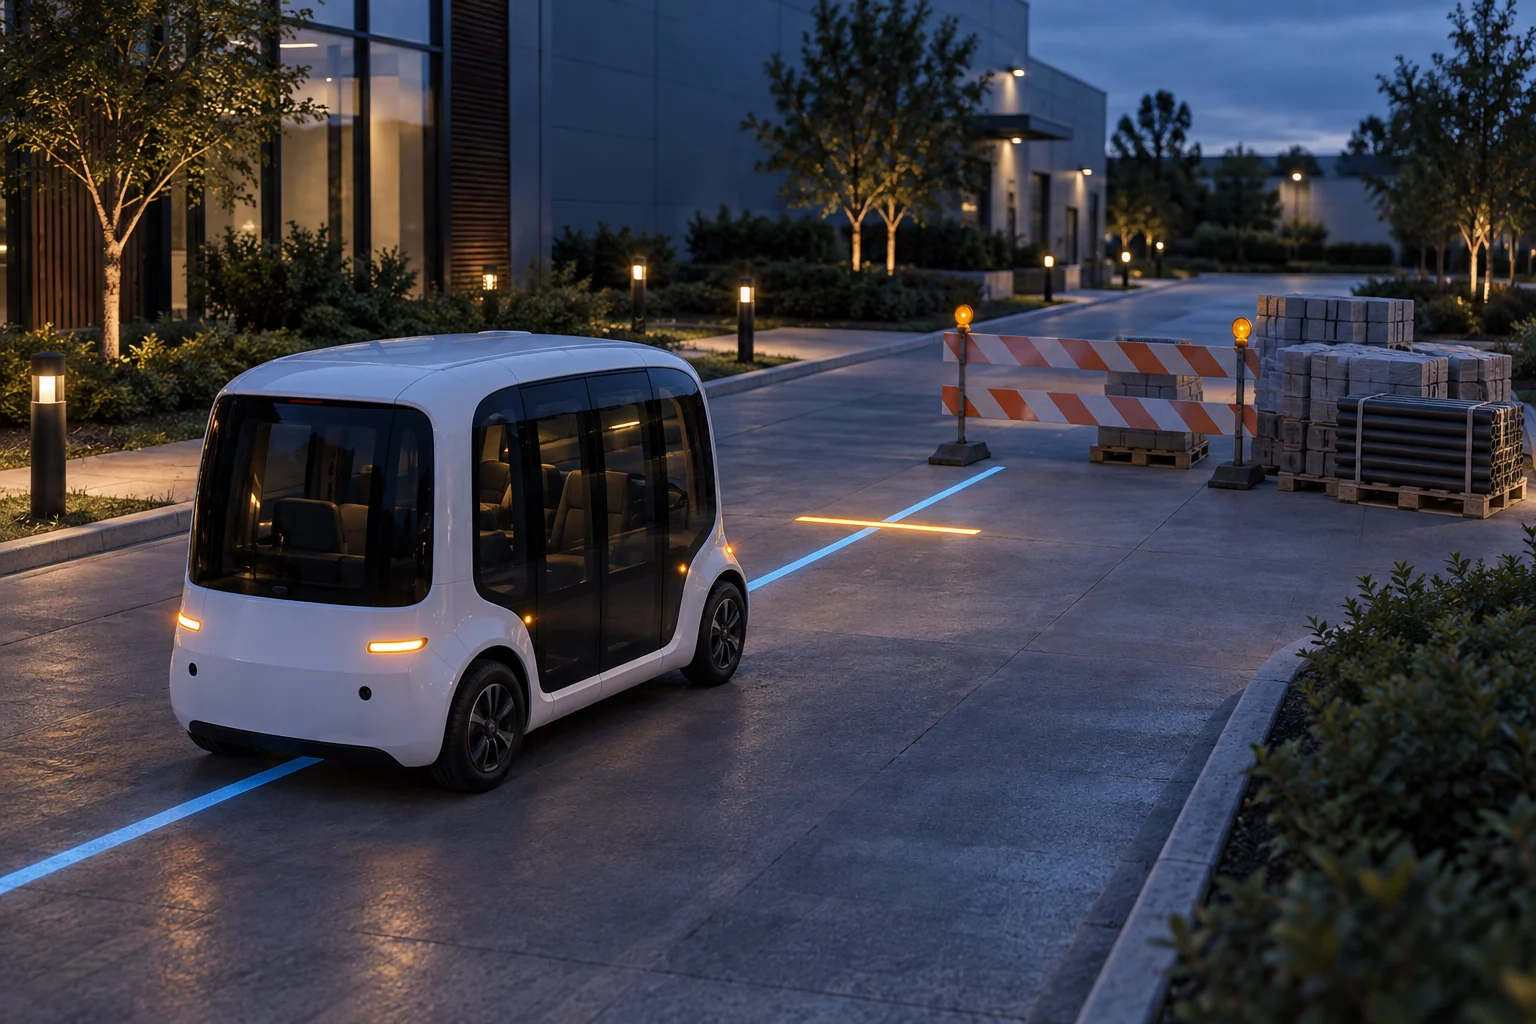
ARLO has the ability to detect obstacles and either stop the machine or determine an alternative route around them within defined operating rules.
Overview
Everything ARLO sees becomes information that can be processed. ARLO continuously has to answer the questions at the heart of autonomous operation:
From those answers ARLO can determine route, direction, speed, stopping position, obstacle avoidance, junction behaviour and mission progression.
“Different missions need different behaviours”
Building a live understanding
ARLO combines all perception and localisation information into a live digital representation of the machine’s surroundings.
The world model is continuously updated as the vehicle moves and conditions change.
This world model contains:
Its position, direction and operating state.
Infrastructure, boundaries, traversable areas and restricted zones.
Moving people, vehicles, equipment and developing hazards.
Planned routes, alternatives, safety zones, stopping distances and confidence levels.
Autonomous control
ARLO uses localisation, mapped route data and decision-making logic to determine how the machine should move through its environment.
It sits between ARLO’s understanding of the world and the mission-specific software that defines where and how the machine operates.
Mission and task management
ARLO is given an operation to complete rather than only a route to follow.
Missions can range from moving baggage or materials and inspecting sites, to selective spraying, perimeter patrol, vegetation clearance and surveying for buried hazards.
The mission-management layer breaks this objective into individual actions, monitors progress and responds to changes.
It can manage:
Sequencing actions, allocating work areas and planning route or coverage.
Controlling tools, attachments and task-specific functions.
Monitoring battery, fuel, payload, charging and refuelling.
Scheduling work, allocating tasks across multiple vehicles and managing return-to-base or recovery procedures.
Defined route autonomy
ARLO supports applications where a machine follows a defined circular route repeatedly.
The current technology was developed for applications such as airport transportation and can incorporate junctions, stops and repeatable operating paths.
Direct route autonomy
ARLO can be configured for movement between defined locations rather than a continuous loop.
That makes it suitable for operations where machines repeatedly move between operational points, such as material handling or depot movements.
Agricultural autonomy
ARLO can be configured specifically for agricultural applications.
He can generate an efficient route across a field after its perimeter is defined, supporting autonomous operations such as ploughing, mowing, seeding and spraying.
Collision avoidance
Perception only creates value when it changes behaviour.
ARLO has the ability to detect obstacles and either stop the machine or determine an alternative route around them within defined operating rules.
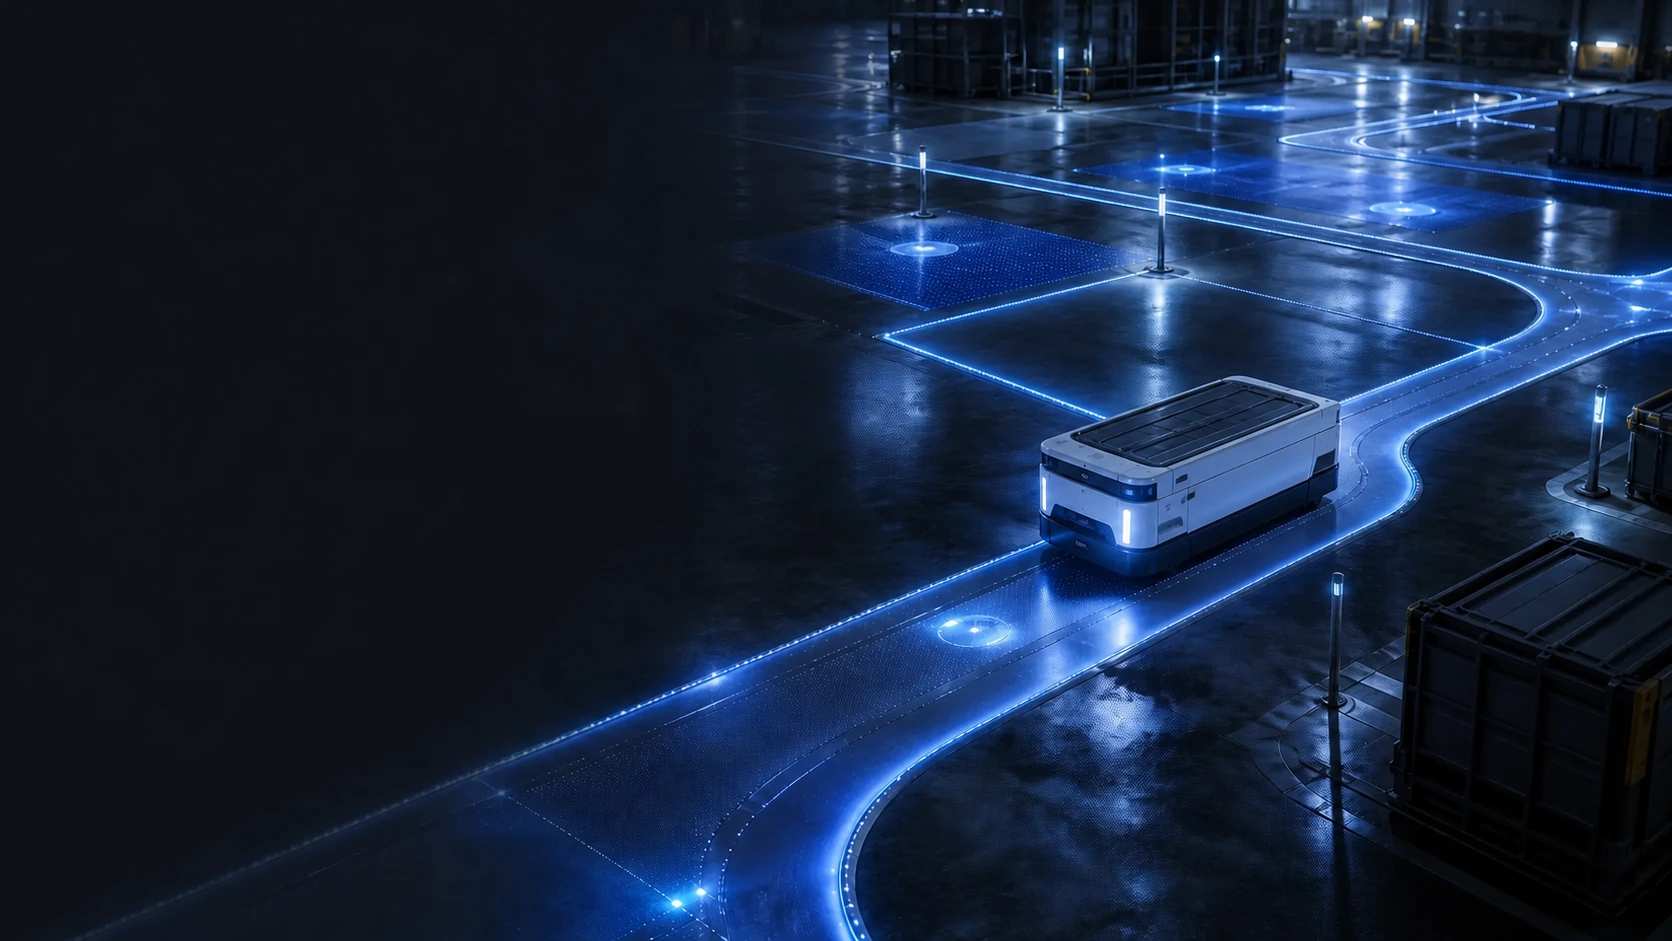
Autonomous operation depends on more than following GPS coordinates. Routes, operating areas, junctions, stopping locations and other site information becomes part of the machine’s operational understanding.
Overview
Watchdog is EVIE’s independent safety and supervisory layer. ARLO performs the autonomous operation; Watchdog continuously checks whether that operation remains safe.
Separating safety supervision from the main autonomy intelligence helps the system detect faults and respond safely if AI processing, sensors or onboard computers fail.
Watchdog can also enforce predefined limits for steering, acceleration and braking, together with approved boundaries and geofenced operating areas.
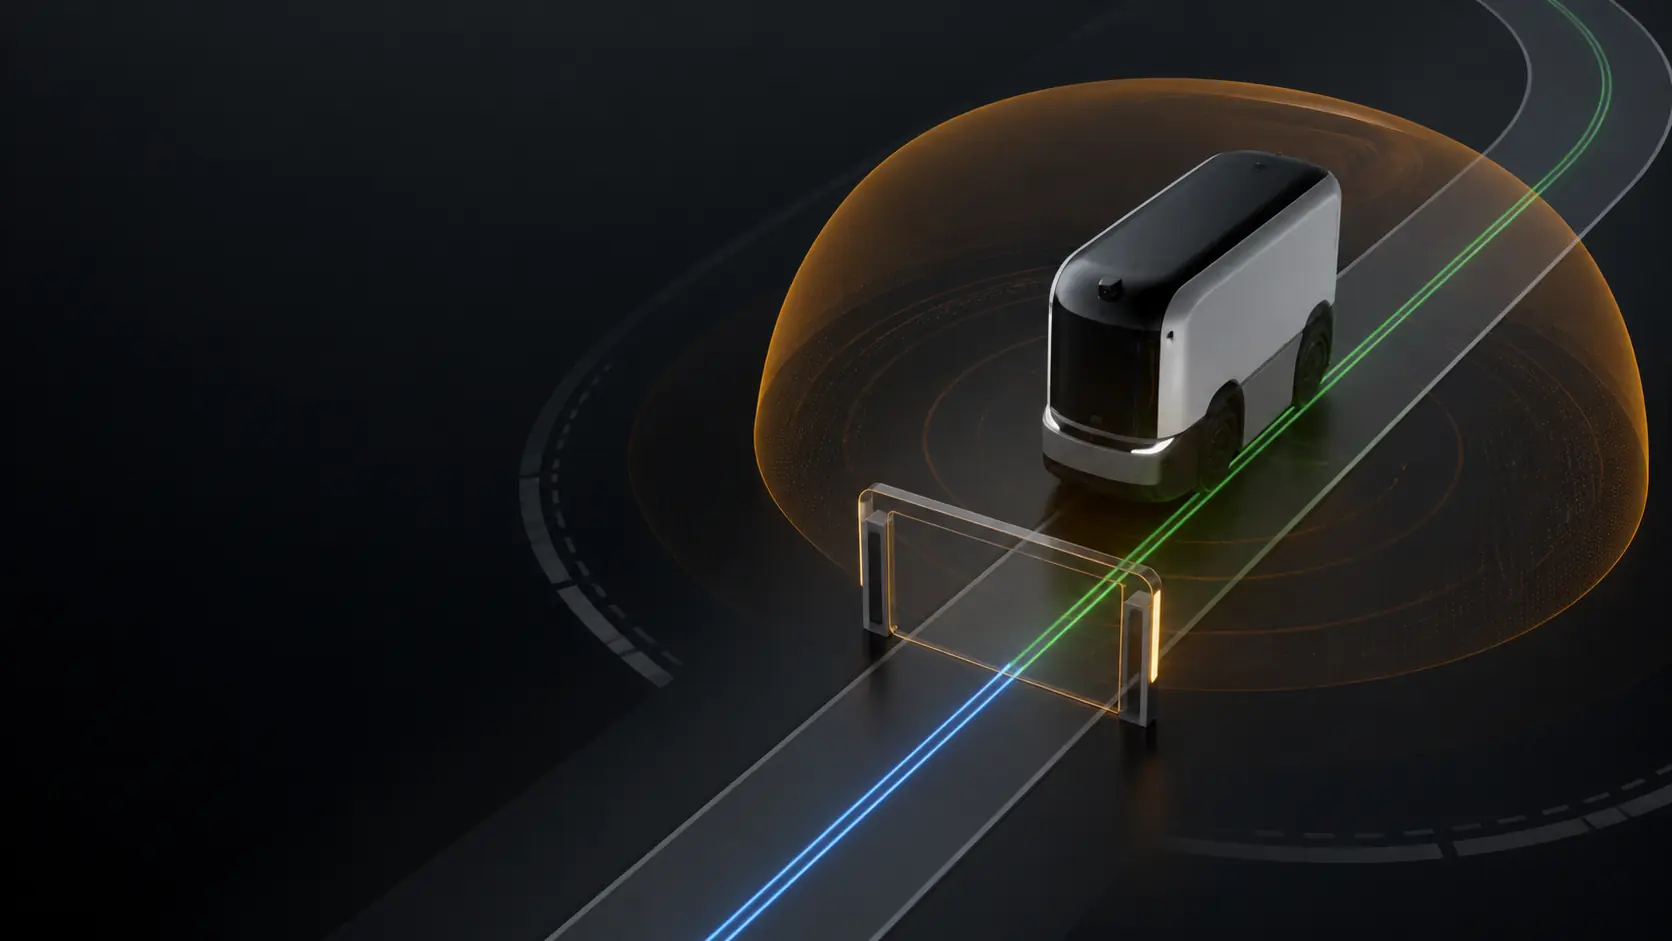
Watchdog Monitors
Watchdog can monitor:
Sensor availability, accuracy, positioning confidence and disagreement between sensors.
Steering, braking, power, speed and direction.
Communications, onboard computing and power systems.
Safety zones, approved routes, operator commands and emergency-stop inputs.
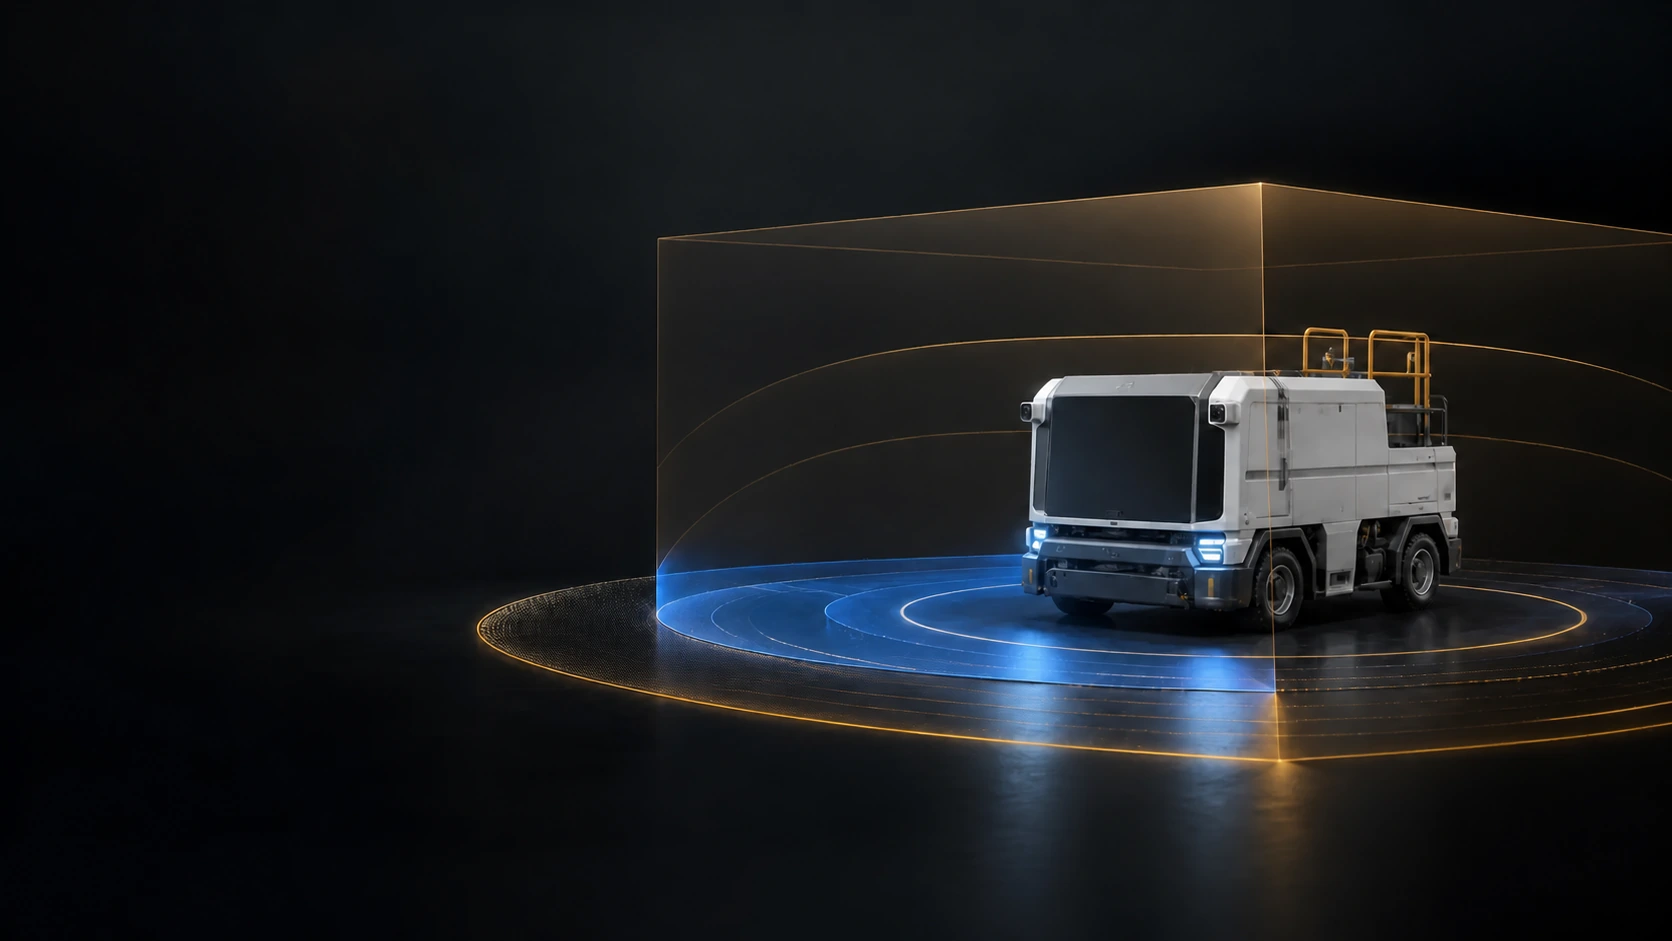
Watchdog Responds
If a problem is detected, Watchdog can:
Limit speed or prevent unsafe commands.
Request replanning or bring the machine to a controlled stop.
Apply emergency stopping where required.
Alert operators and log the event.
Overview
Watchdog is EVIE’s independent safety and supervisory layer. ARLO performs the autonomous operation; Watchdog continuously checks whether that operation remains safe.
Separating safety supervision from the main autonomy intelligence helps the system detect faults and respond safely if AI processing, sensors or onboard computers fail.
Watchdog can also enforce predefined limits for steering, acceleration and braking, together with approved boundaries and geofenced operating areas.
Watchdog Monitors
Watchdog can monitor:
Sensor availability, accuracy, positioning confidence and disagreement between sensors.
Steering, braking, power, speed and direction.
Communications, onboard computing and power systems.
Safety zones, approved routes, operator commands and emergency-stop inputs.
Watchdog Responds
If a problem is detected, Watchdog can:
Limit speed or prevent unsafe commands.
Request replanning or bring the machine to a controlled stop.
Apply emergency stopping where required.
Alert operators and log the event.
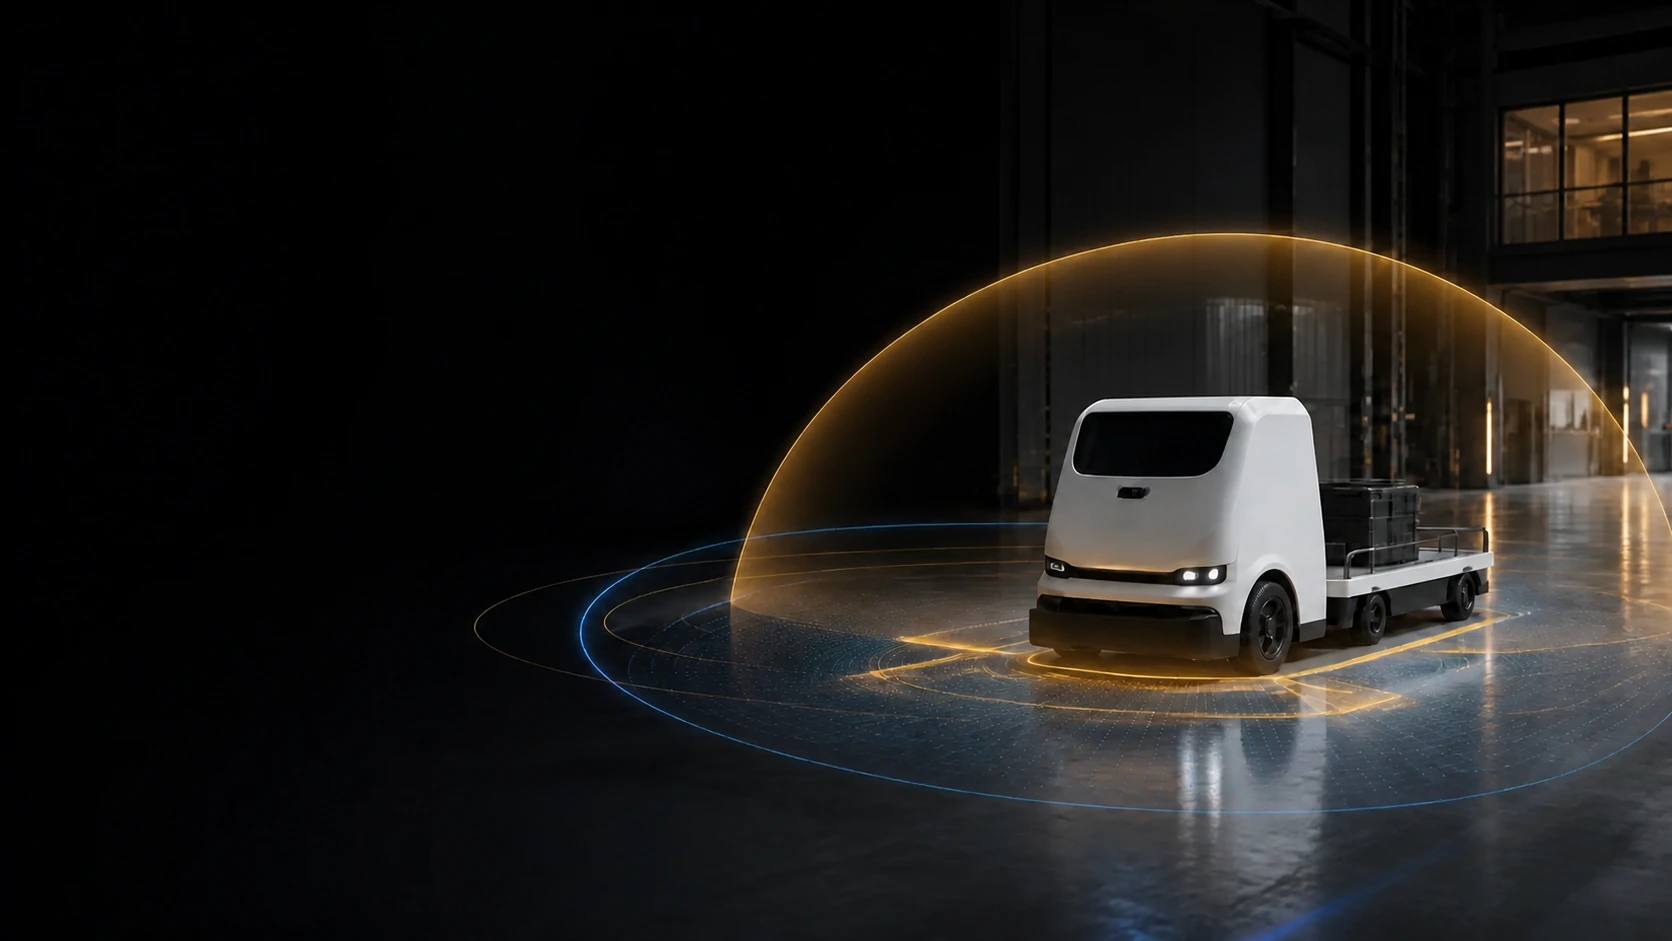
Overview
ARLO converts its selected trajectory and task into commands the machine can carry out.
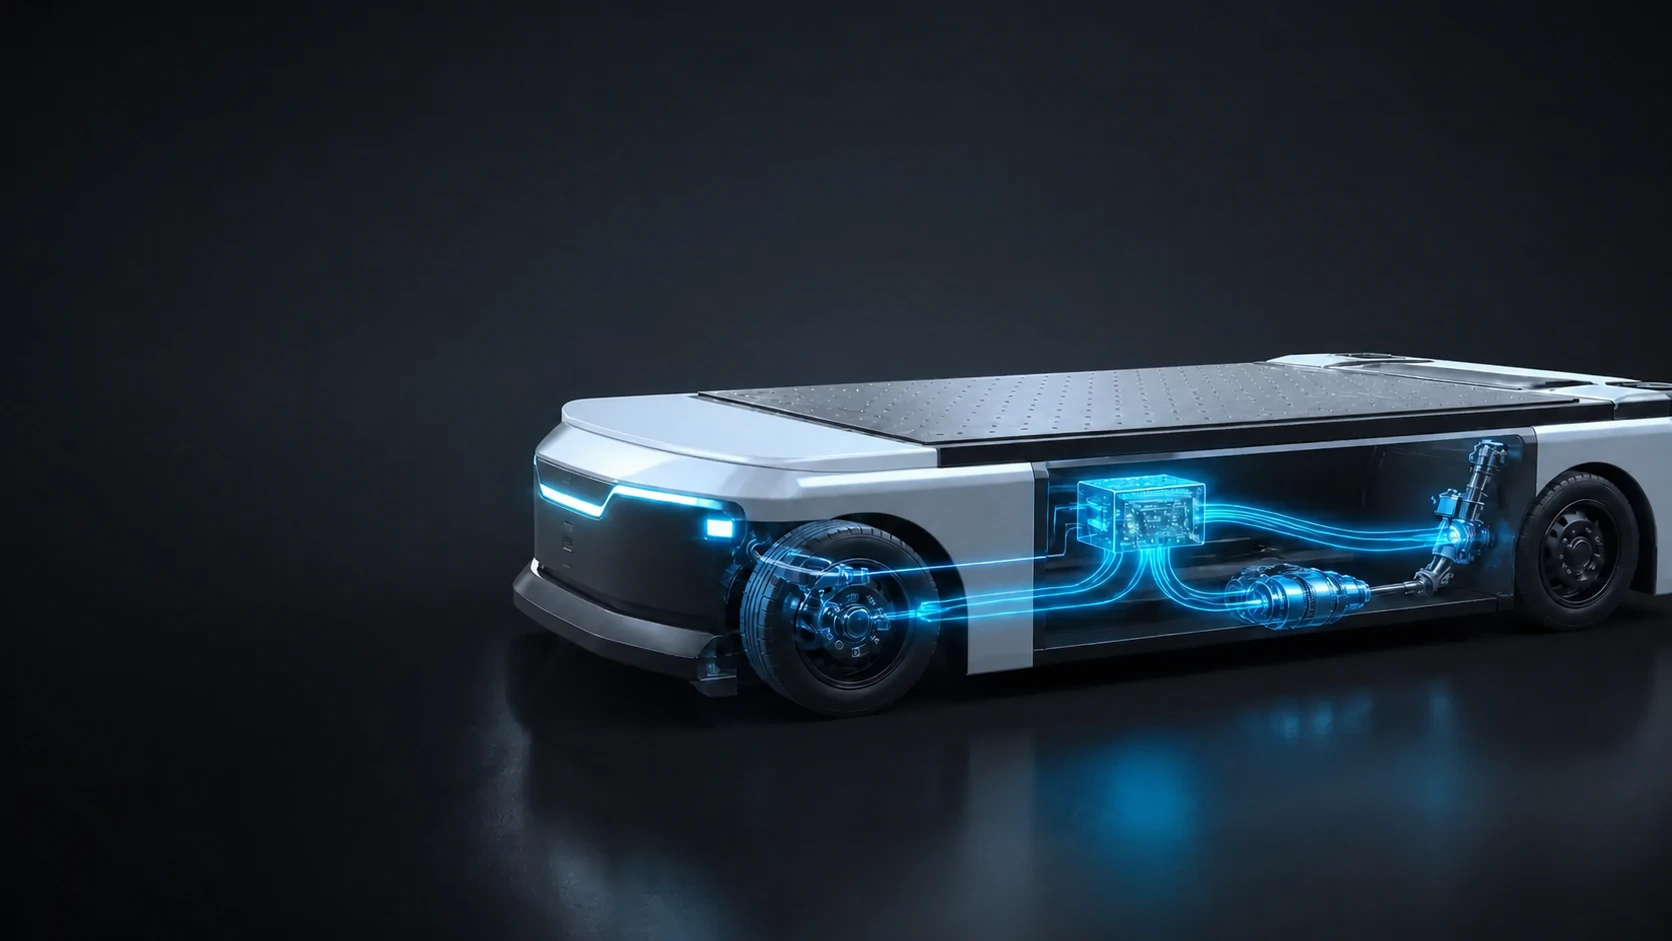
Depending on the platform, this can include:
What ARLO Can Control
ARLO can control:
Steering, throttle or power demand, braking and transmission.
Parking brake, lights and warning systems.
Hydraulics and power take-off.
Robotic implements and application-specific equipment.
Spraying, cutting, lifting, loading and similar machine functions.
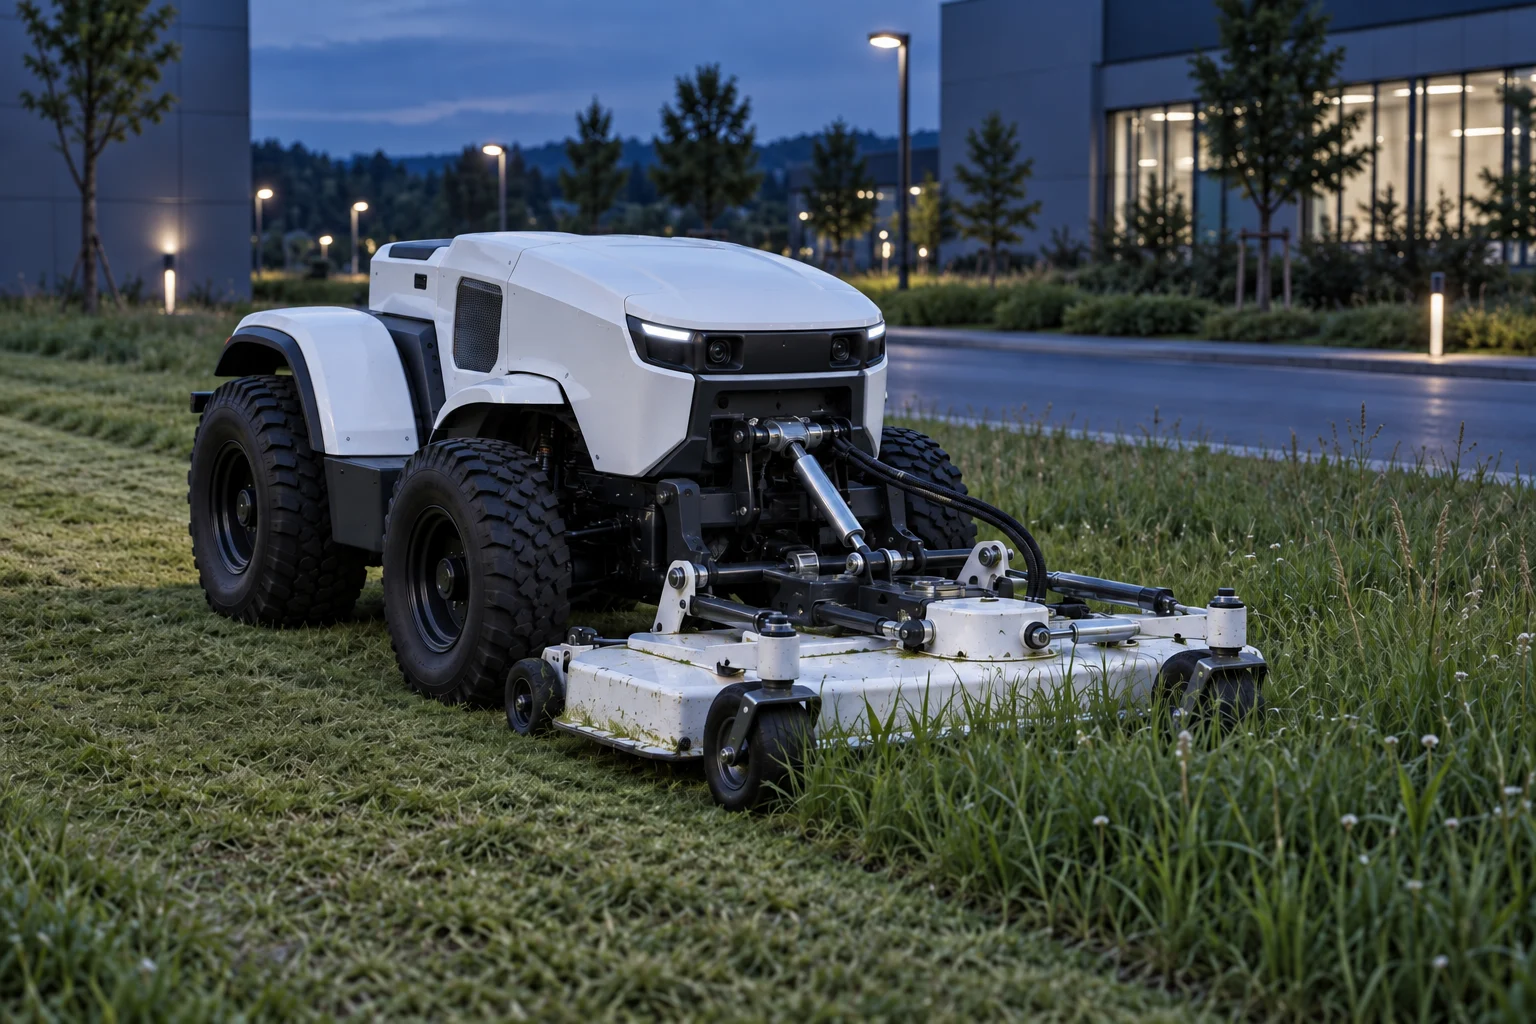
How ARLO Integrates
ARLO integrates via:
CAN bus and automotive Ethernet.
ECUs and drive-by-wire interfaces.
Electronic actuators and digital or analogue I/O.
Where required.
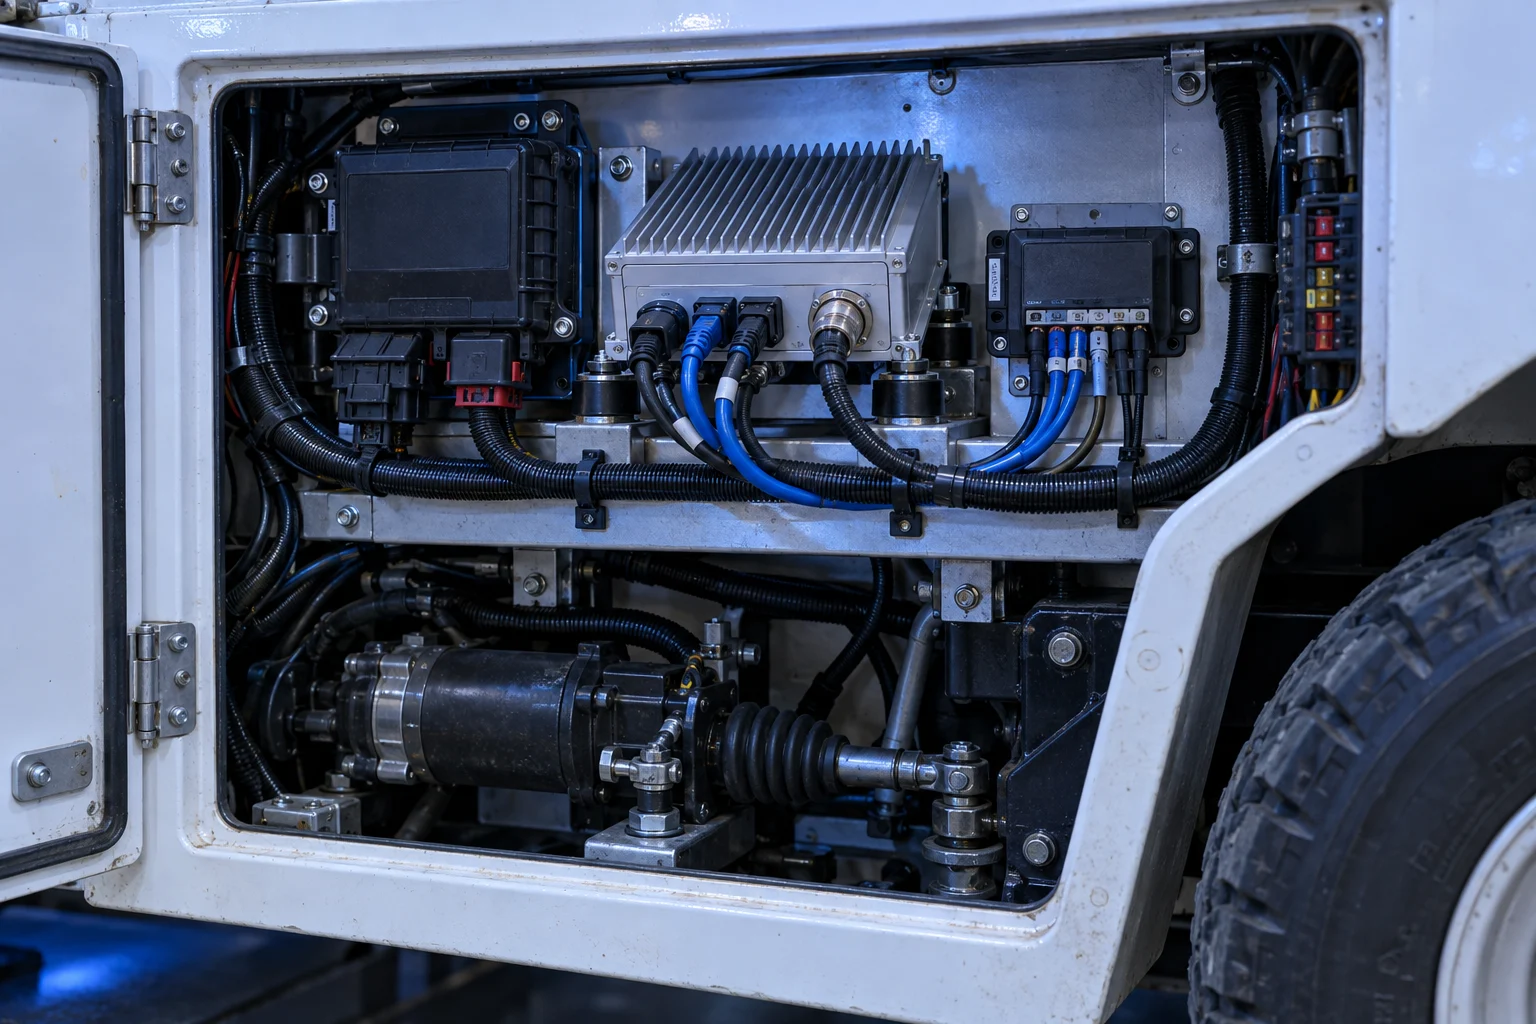
One autonomy stack. Different machines.
The vehicle-interface layer allows ARLO to be used across different manufacturers and machine types without redesigning the entire autonomy stack.
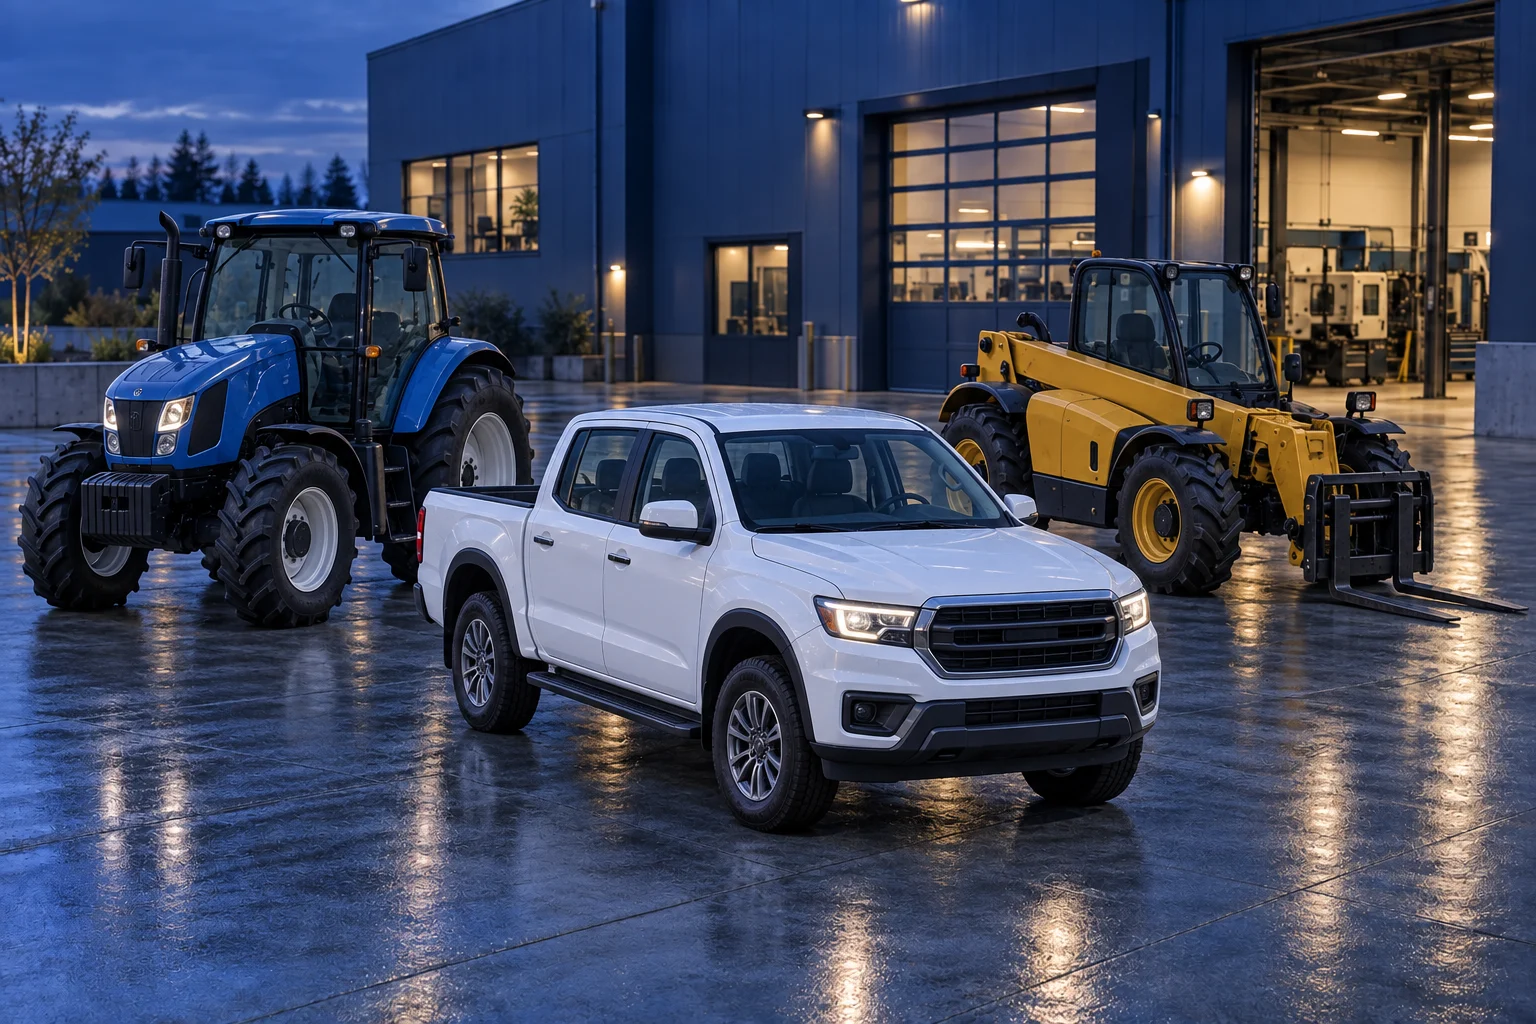
Machine control
The machine does not need to understand autonomy. ARLO gives it the instructions it needs to move.
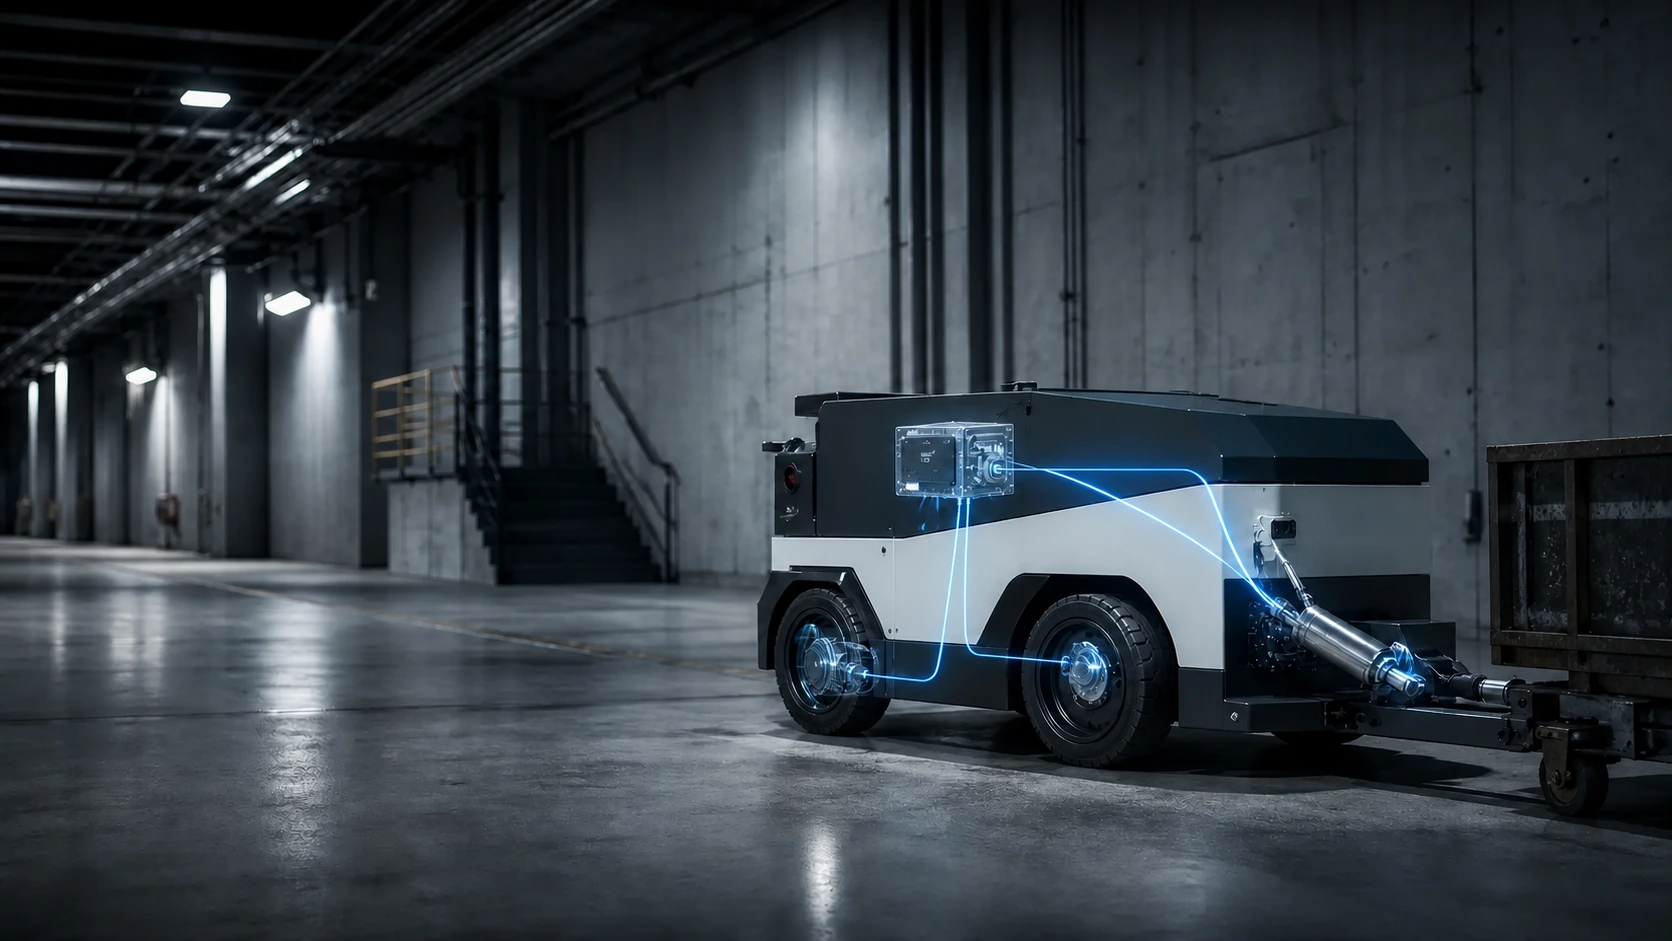
ARLO decides how to move. The platform determines what makes it move, whether it be:
Overview
ARLO converts its selected trajectory and task into commands the machine can carry out.
Depending on the platform, this can include:
What ARLO Can Control
ARLO can control:
Steering, throttle or power demand, braking and transmission.
Parking brake, lights and warning systems.
Hydraulics and power take-off.
Robotic implements and application-specific equipment.
Spraying, cutting, lifting, loading and similar machine functions.
How ARLO Integrates
ARLO integrates via:
CAN bus and automotive Ethernet.
ECUs and drive-by-wire interfaces.
Electronic actuators and digital or analogue I/O.
Where required.
One autonomy stack. Different machines.
The vehicle-interface layer allows ARLO to be used across different manufacturers and machine types without redesigning the entire autonomy stack.
Machine control
The machine does not need to understand autonomy. ARLO gives it the instructions it needs to move.
ARLO decides how to move. The platform determines what makes it move, whether it be:
Beyond seeing, thinking and acting, our wider technology ecosystem connects machines, protects data, supports operators and helps autonomous systems develop and scale.
Overview
Machines can be connected to our wider operational infrastructure for monitoring, telemetry, fleet management and communication.
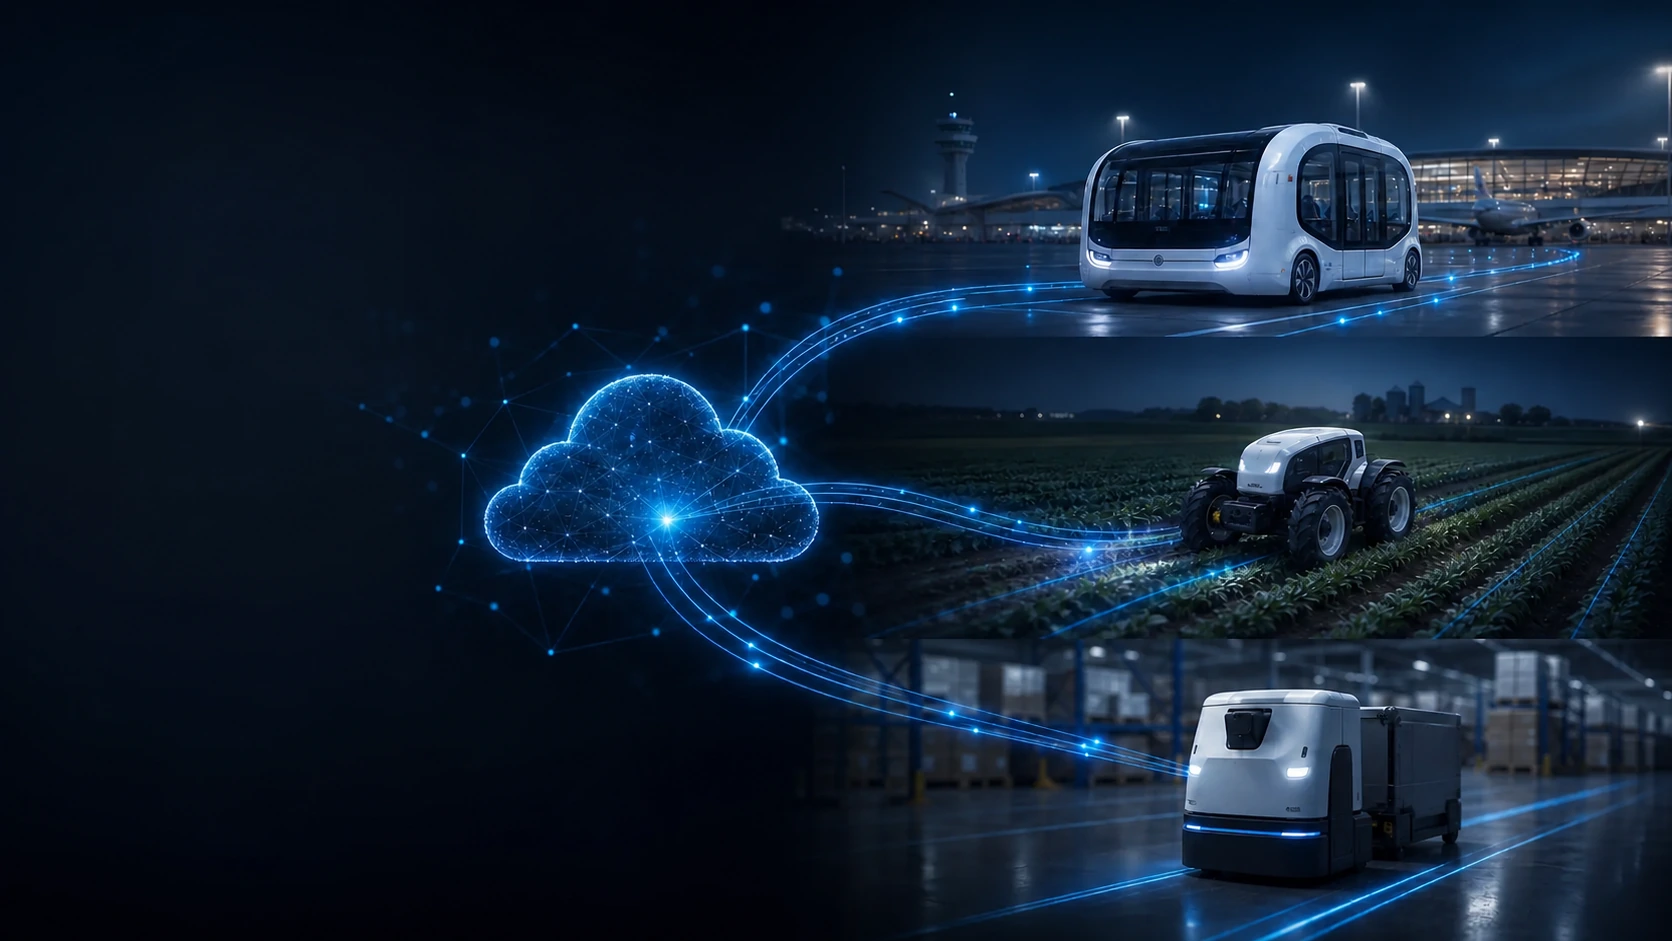
Machine connectivity
Depending on the application, ARLO can communicate using private or public cellular networks, Wi-Fi, long-range radio, mesh networks, satellite communications or wired service connections.
Loss of communication does not automatically mean loss of control. ARLO’s core perception, navigation and safety processing remains onboard. If communication is lost, the configured response may be to continue a low-risk task, stop safely or return to a predefined location.
The connection supports two-way exchange of telemetry, messages, mission instructions and routing changes between the machine and authorised monitoring systems.
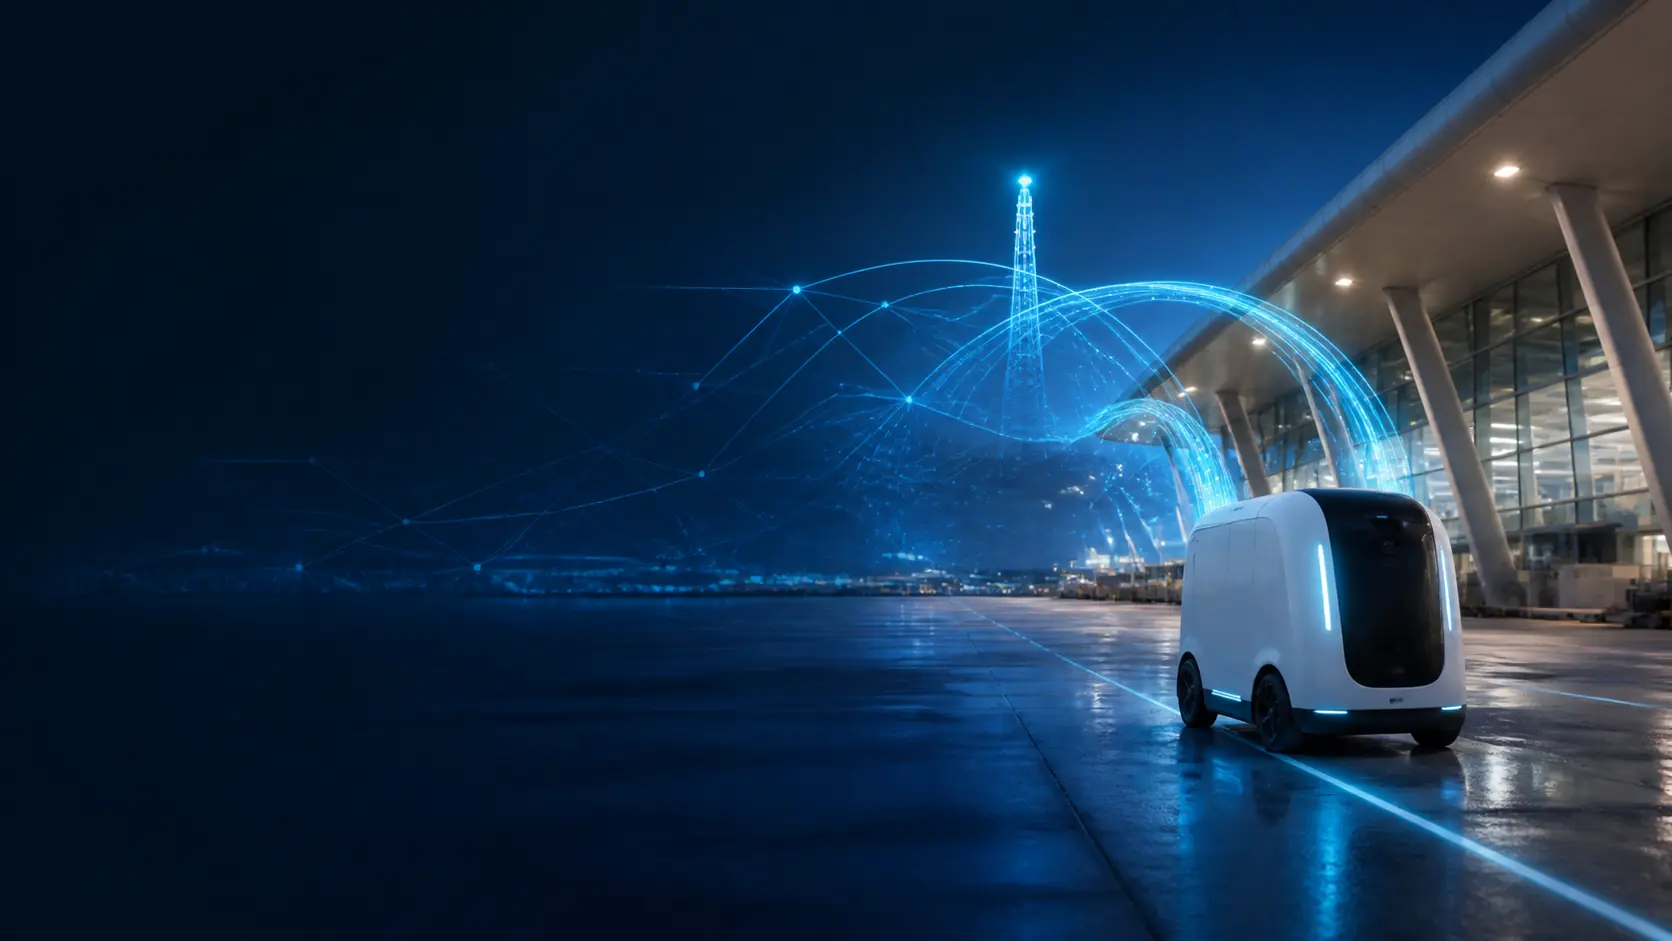
Connected data
EVIE’s connected data infrastructure securely exchanges information between autonomous machines and monitoring systems.
Working with the machine’s communication systems, it sends data to an online server where it can be accessed by fleet-management systems and used to send instructions back to connected vehicles.
Fleet management
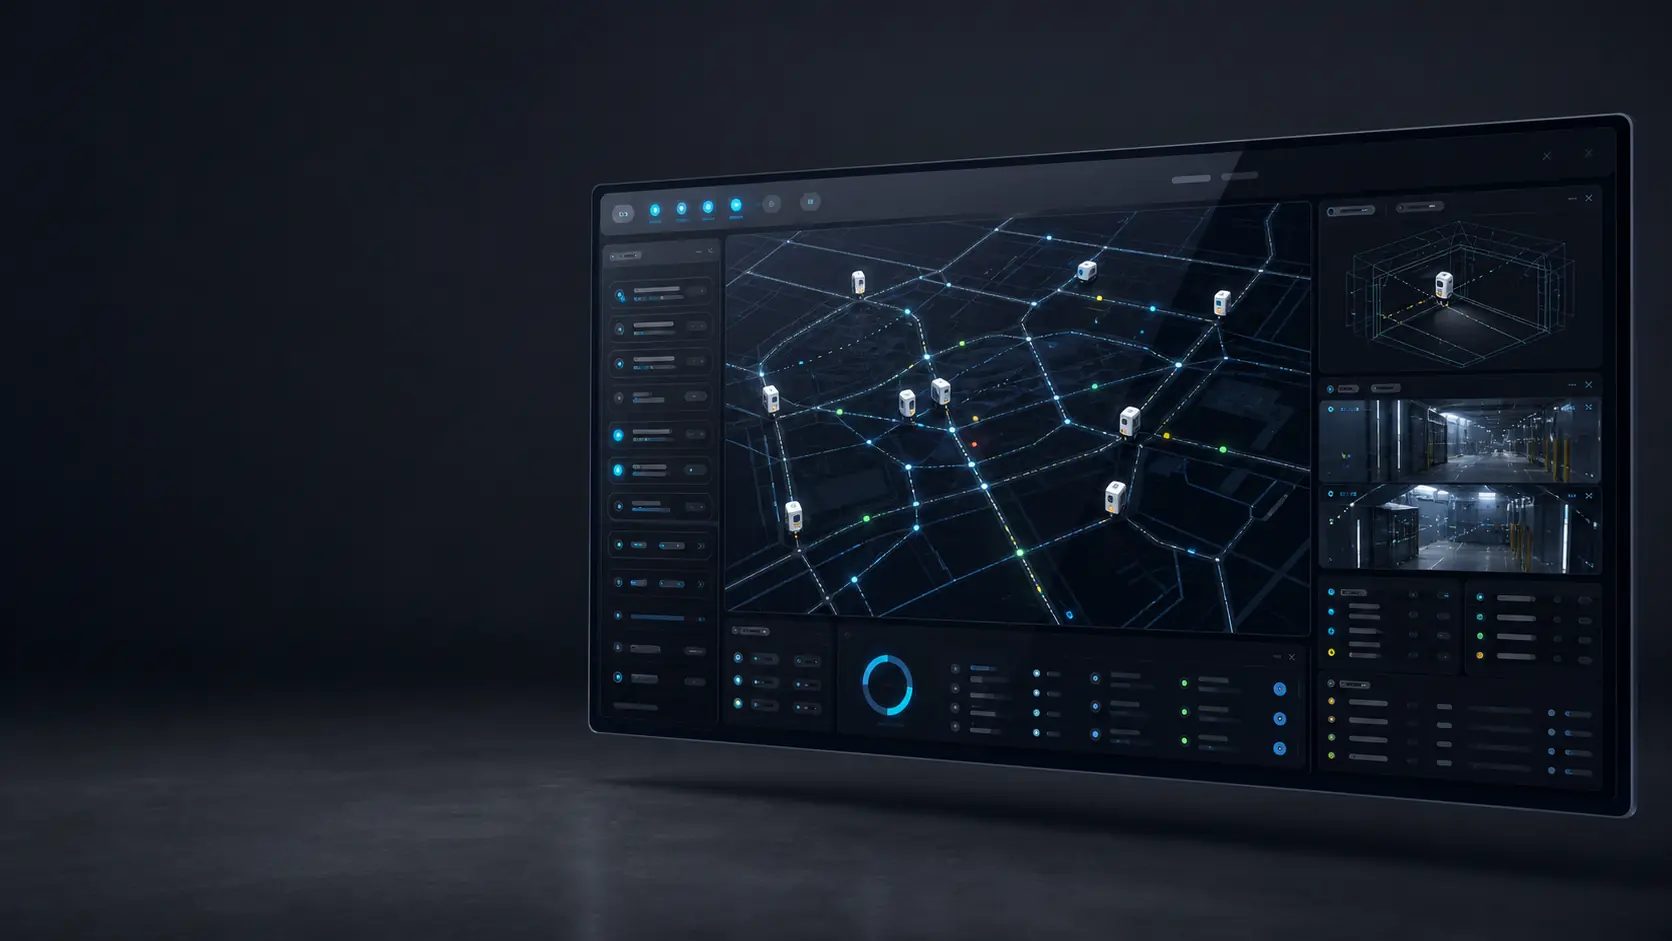
Our fleet-management system monitors connected autonomous machines.
It monitors the location and status of multiple machines and uses two-way 5G communication to support routing and operating changes in real time.
Cyber security
Once autonomous machines become connected machines, communications have to be protected.
Our current architecture uses AES-256 encryption to protect telemetry exchanged between autonomous machines and fleet-management infrastructure.
Protects transmitted telemetry.
Security beyond telemetry encryption
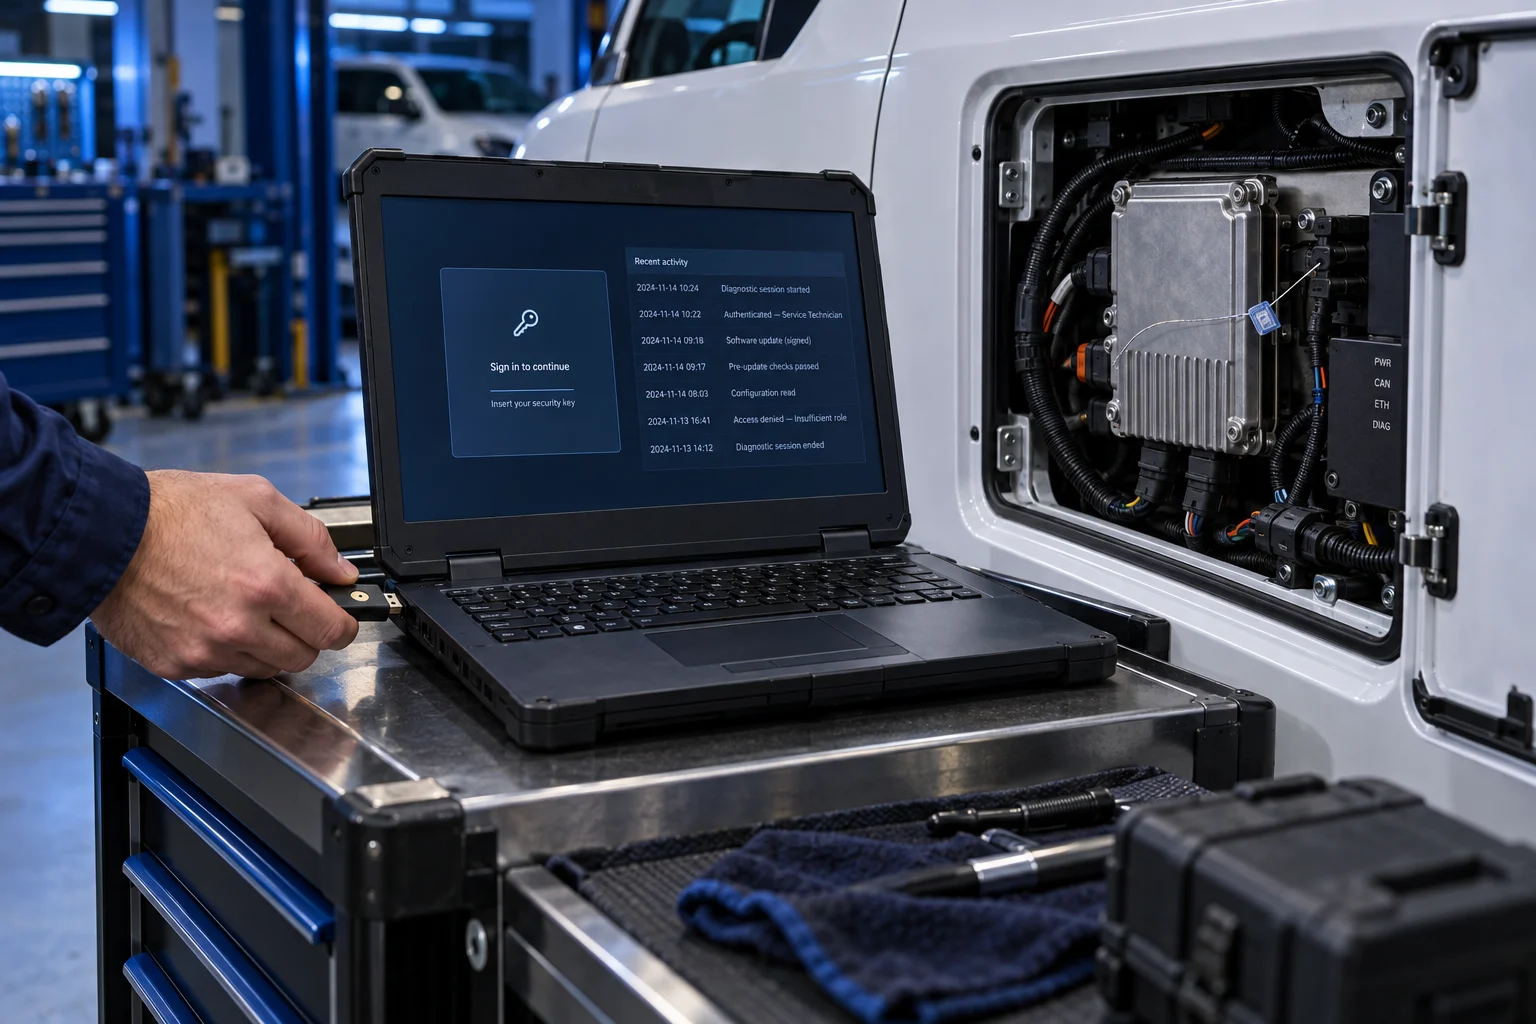
Beyond telemetry encryption and key management, the technology stack can include:
Secure boot and signed software or AI-model updates.
Device authentication and role-based user permissions.
Segmentation and secure CAN or vehicle gateways.
Tamper detection, intrusion monitoring and complete command/event logs.
Critical driving and safety commands are protected from unauthorised access, while operational records provide an auditable history of the machine’s actions.
Human oversight
Authorised users may be able to:
Start, pause, cancel or assign work.
Define work zones and exclusions.
Approve unusual manoeuvres or use authorised teleoperation where available.
Initiate a safe stop and inspect recorded events.
The aim is supervised autonomy: ARLO carries out normal work itself and asks for assistance only when it encounters a situation outside its approved operating capability.
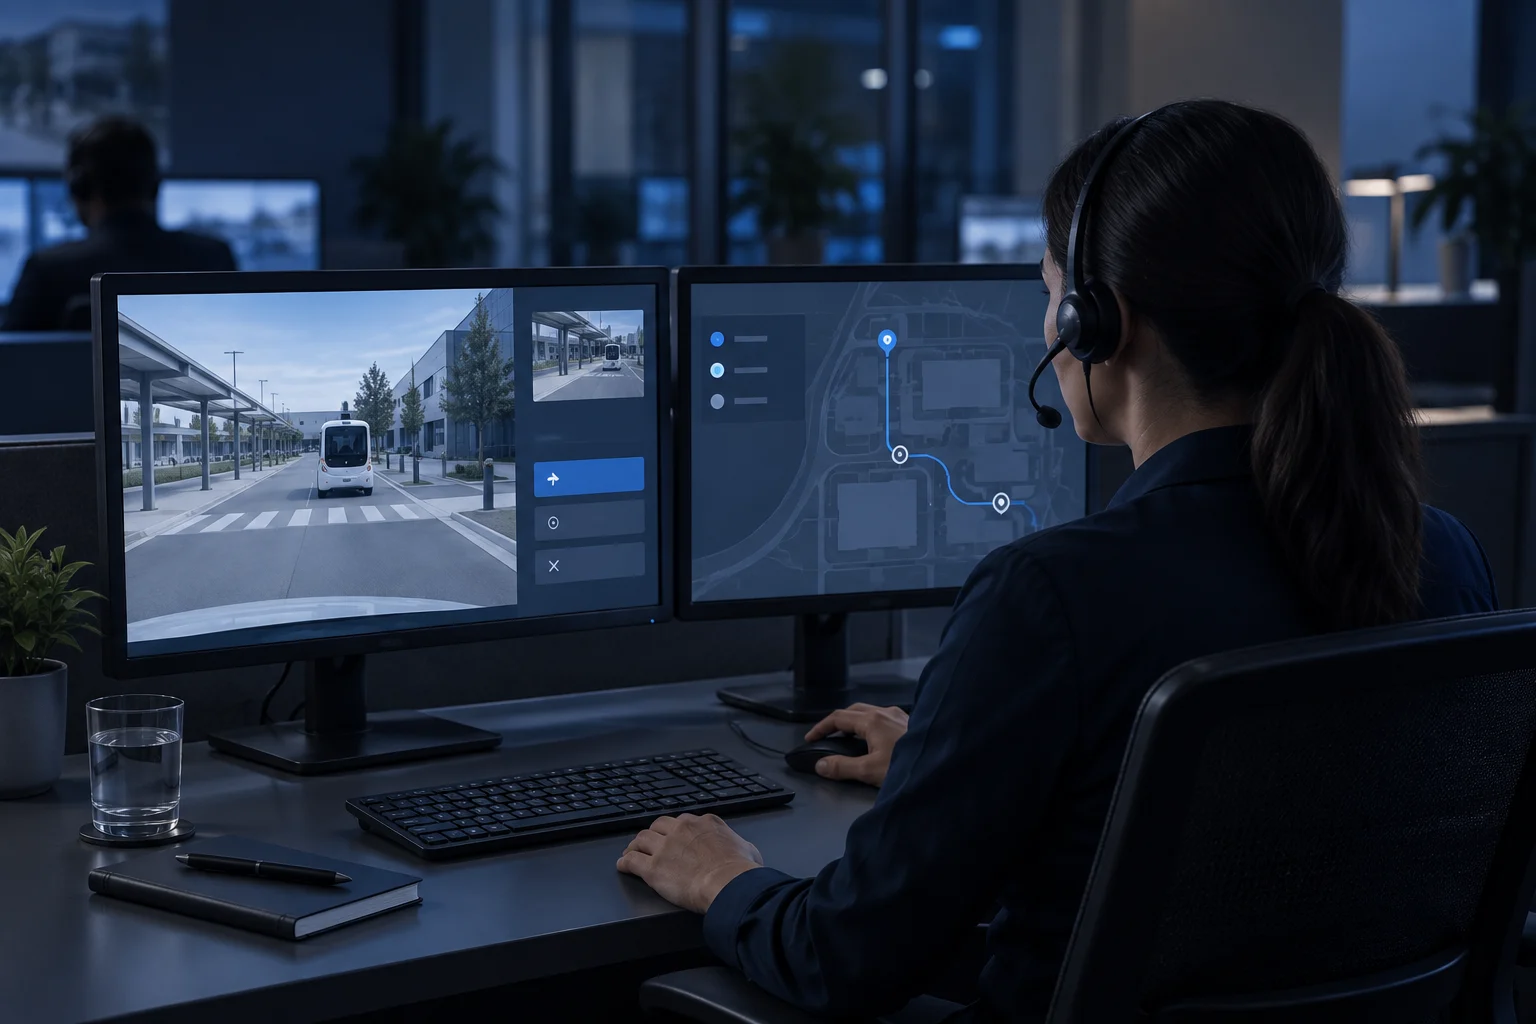
ARLO can be supervised locally or remotely through a control interface. The interface can show:
Machine position, route, task and progress.
Operational reporting and model improvement
Selected data can be securely uploaded for reporting, fleet optimisation, maintenance planning and improvement of AI models. Updated models are tested and approved before controlled deployment to vehicles.
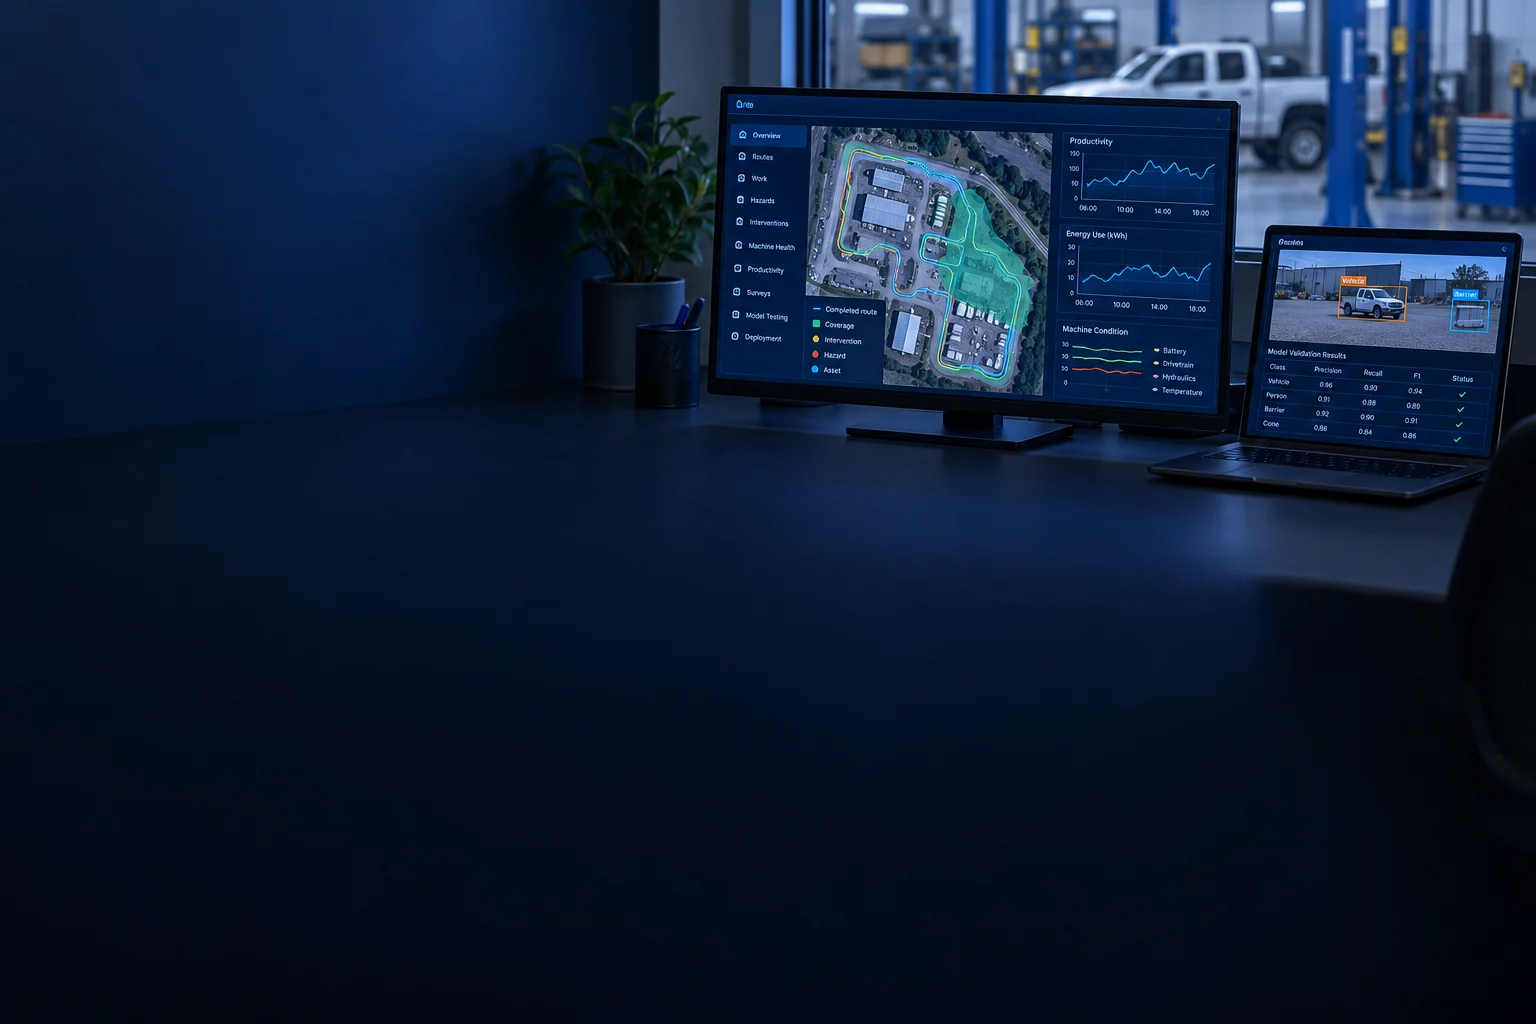
ARLO records operational information including:
Routes, areas covered, completed tasks and incomplete work.
Overview
Machines can be connected to our wider operational infrastructure for monitoring, telemetry, fleet management and communication.
Machine connectivity
Depending on the application, ARLO can communicate using private or public cellular networks, Wi-Fi, long-range radio, mesh networks, satellite communications or wired service connections.
Loss of communication does not automatically mean loss of control. ARLO’s core perception, navigation and safety processing remains onboard. If communication is lost, the configured response may be to continue a low-risk task, stop safely or return to a predefined location.
The connection supports two-way exchange of telemetry, messages, mission instructions and routing changes between the machine and authorised monitoring systems.
Connected data
EVIE’s connected data infrastructure securely exchanges information between autonomous machines and monitoring systems.
Working with the machine’s communication systems, it sends data to an online server where it can be accessed by fleet-management systems and used to send instructions back to connected vehicles.
Fleet management
Our fleet-management system monitors connected autonomous machines.
It monitors the location and status of multiple machines and uses two-way 5G communication to support routing and operating changes in real time.
Cyber security
Once autonomous machines become connected machines, communications have to be protected.
Our current architecture uses AES-256 encryption to protect telemetry exchanged between autonomous machines and fleet-management infrastructure.
Protects transmitted telemetry.
Encryption keys are generated securely and stored within Hardware Security Modules.
Asymmetric cryptography such as RSA or ECC can be used to establish secure key exchange.
Encryption keys can be changed periodically to maintain security.
Updated keys are distributed through protected channels to authorised systems.
Security beyond telemetry encryption
Beyond telemetry encryption and key management, the technology stack can include:
Secure boot and signed software or AI-model updates.
Device authentication and role-based user permissions.
Segmentation and secure CAN or vehicle gateways.
Tamper detection, intrusion monitoring and complete command/event logs.
Critical driving and safety commands are protected from unauthorised access, while operational records provide an auditable history of the machine’s actions.
Human oversight
Authorised users may be able to:
Start, pause, cancel or assign work.
Define work zones and exclusions.
Approve unusual manoeuvres or use authorised teleoperation where available.
Initiate a safe stop and inspect recorded events.
The aim is supervised autonomy: ARLO carries out normal work itself and asks for assistance only when it encounters a situation outside its approved operating capability.
ARLO can be supervised locally or remotely through a control interface. The interface can show:
Machine position, route, task and progress.
Detected objects, hazards, camera and radar views.
Health, alerts and intervention requests.
Completed work, remaining work, evidence and reports.
Operational reporting and model improvement
Selected data can be securely uploaded for reporting, fleet optimisation, maintenance planning and improvement of AI models. Updated models are tested and approved before controlled deployment to vehicles.
ARLO records operational information including:
Routes, areas covered, completed tasks and incomplete work.
Detected hazards, interventions and emergency events.
Vehicle condition, sensor health, time, distance, energy and productivity.
Surface and subsurface findings where relevant.
Intelligence where it’s needed
ARLO performs its core intelligence locally on the machine using compact embedded processing and an in-house software environment designed for real-time autonomous operation.
Low-latency onboard processing supports rapid perception, decision-making and autonomous response.
Compact embedded processing keeps core autonomy close to the machine while reducing dependence on remote infrastructure.
ARLO’s software architecture can process multiple autonomous functions at the same time to support real-time operation.
Perception, AI and decision-making can run locally on the machine without relying on a permanent cloud connection.
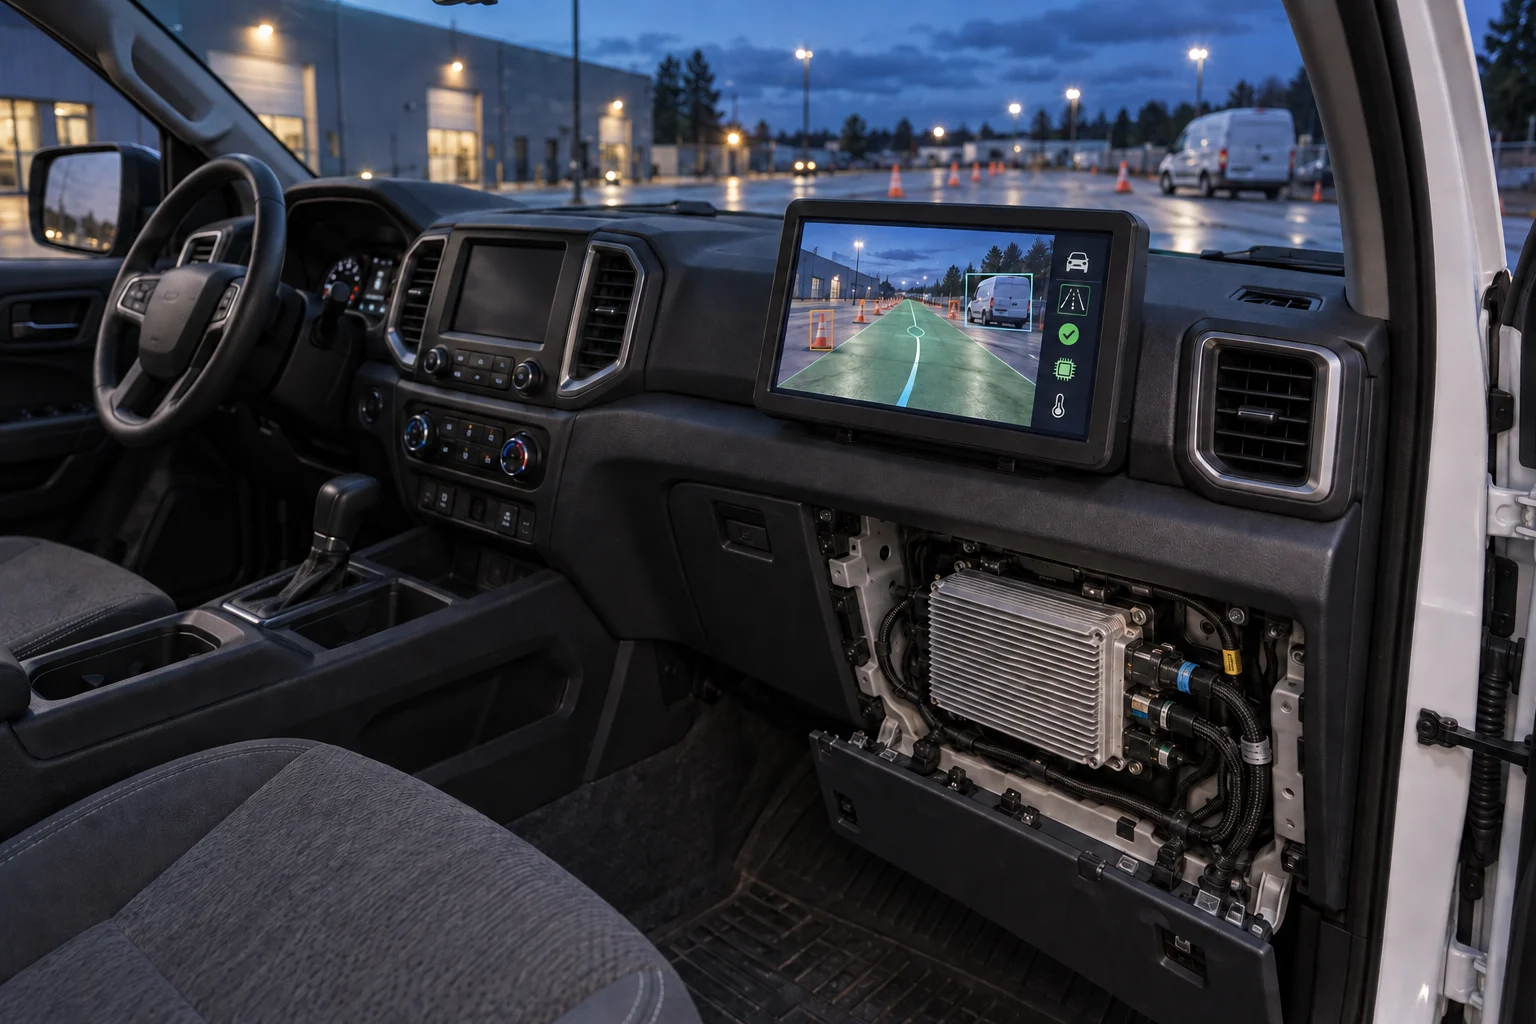
Onboard AI
ARLO’s onboard AI can handle perception, segmentation, object tracking, terrain and free-space understanding, anomaly detection, behaviour prediction, route selection, mission optimisation and system-health monitoring.
Onboard AI
ARLO’s onboard AI can handle perception, segmentation, object tracking, terrain and free-space understanding, anomaly detection, behaviour prediction, route selection, mission optimisation and system-health monitoring.
Models can be configured for the machine, working environment and operation required.
Development environment
Our in-house development environment sits at the foundation of much of our autonomous software technology.
It uses our own object-based graphical programming approach for developing real-time autonomous applications. Complete machine simulations can be run in the lab before the same source code is deployed onto the physical machine.
During controlled development and testing, engineers can observe and refine real-time applications while evaluating the machine’s autonomous behaviour. Software and AI-model updates are tested and approved before controlled deployment to operational vehicles.
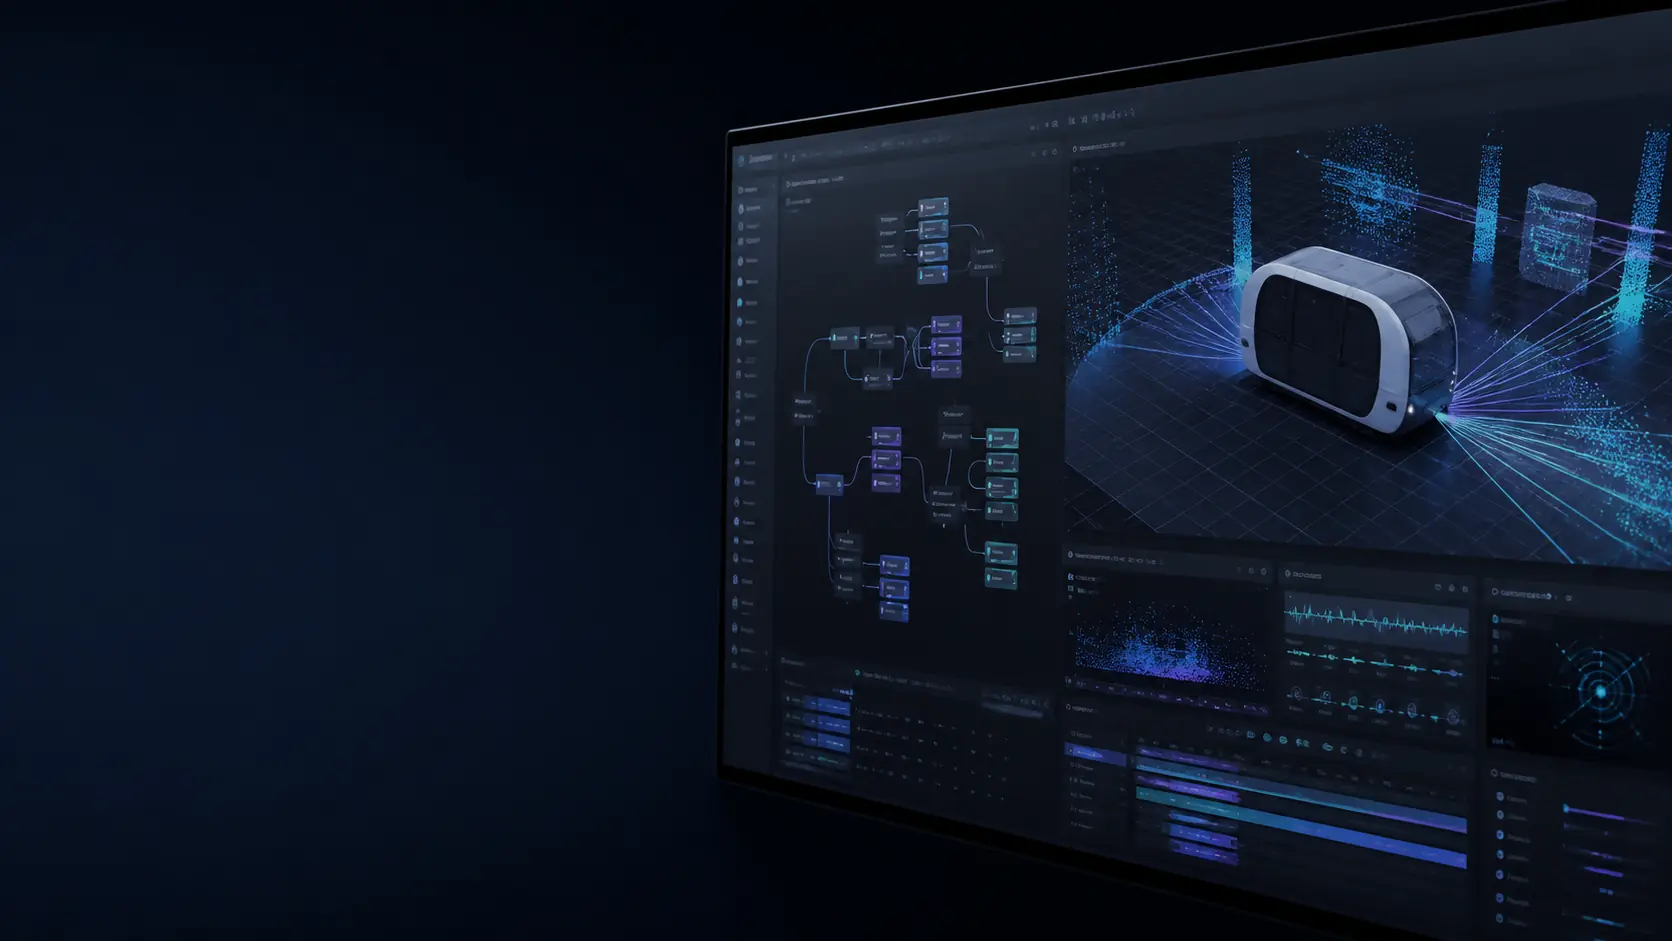
Build virtually. Prove physically.
Develop and test autonomous behaviour virtually before deployment.
High-speed testing
Our autonomous technology can be used for high-speed testing on race tracks in a controlled environment.
The software calculates the racing line, enabling autonomous vehicles to be tested at increased speeds while engineers assess vehicle dynamics through corners and other demanding parts of a circuit.
Development environment
Our in-house development environment sits at the foundation of much of our autonomous software technology.
It uses our own object-based graphical programming approach for developing real-time autonomous applications. Complete machine simulations can be run in the lab before the same source code is deployed onto the physical machine.
During controlled development and testing, engineers can observe and refine real-time applications while evaluating the machine’s autonomous behaviour. Software and AI-model updates are tested and approved before controlled deployment to operational vehicles.
Build virtually. Prove physically.
Develop and test autonomous behaviour virtually before deployment.
Move the same software architecture from simulation onto the physical machine.
Observe and modify real-time applications during development and testing.
High-speed testing
Our autonomous technology can be used for high-speed testing on race tracks in a controlled environment.
The software calculates the racing line, enabling autonomous vehicles to be tested at increased speeds while engineers assess vehicle dynamics through corners and other demanding parts of a circuit.
Autonomy tested where
movement becomes demanding

Autonomy is not one technology. It is a system of technologies continuously working together.
Find clear answers to common questions about how EVIE’s technology stack sees, thinks, connects, protects and turns decisions into autonomous movement.
ARLO acts as the intelligent operator by receiving information from the machine’s/asset’s sensors, understanding the surroundings and deciding how the task should be completed. It then sends commands to the machine’s steering, braking, acceleration, hydraulic or other control systems.
Watchdog operates independently as the safety supervisor by continually monitoring ARLO, the machine/asset and the surrounding environment. If anything moves outside the permitted operating or safety limits, Watchdog can override the command, slow the machine, stop it or place it into a safe state.
ARLO combines information from AI cameras, 4D radar and the machine’s own sensors. Depending on the application, this can also include GNSS or RTK positioning, inertial measurement, wheel-speed data, encoders and other task-specific sensors. This information is processed through sensor fusion, creating a reliable, real-time understanding of the machine’s position, surrounding objects, people, vehicles, terrain and potential hazards.
AI-enhanced 4D radar is specifically focused on detecting and tracking physical objects. It measures their distance, direction, height and velocity, including in darkness, dust, fog, rain and other difficult conditions. EVIE’s wider AI systems use this radar information alongside cameras and other sensors to understand the complete situation. They determine where the machine is, interpret what is happening, plan the safest route and control the machine’s actions. The key difference: 4D radar provides critical perception data; ARLO turns that data into intelligent decisions and movement.
EVIE uses multiple positioning methods rather than relying on a single source. These can include GNSS or high-accuracy RTK positioning, inertial sensors, vehicle odometry, digital maps and visual or radar-based localisation. ARLO compares this information with the assigned route, working area or task plan. It continually calculates the machine’s position and adjusts its route as it moves.
Where satellite positioning is unreliable or unavailable, EVIE’s localisation technology can use the machine’s movement and surrounding features to maintain an accurate understanding of its location.
ARLO identifies the object, assesses its position and movement, and determines the level of risk. Depending on the situation, it can reduce speed, maintain a safe distance, plan an alternative route or bring the machine to a controlled stop.
Watchdog independently checks that ARLO’s response remains safe. If the hazard cannot be resolved confidently, the system defaults to a safe state and can request assistance from a remote operator or supervisor.
Safety and security are built into the complete system architecture. ARLO processes critical information directly on the machine, reducing latency and removing the need to depend on a continuous cloud connection. Watchdog independently supervises the machine’s behaviour, while defined operating limits, system-health monitoring, access controls, secure communications, controlled software updates and event logging help protect the system. If a fault, communication loss or abnormal condition is detected, the machine can automatically slow down, stop or enter a predefined safe state.
Yes, EVIE’s technology is designed to be machine, powertrain and sector agnostic. ARLO can be integrated with electric, combustion, hybrid and hydraulic platforms, including both new machines and existing fleets. The core autonomy and safety technology remains consistent, while the sensors, controls and operating software are configured for each machine, task and environment. This allows customers to begin with one application and then scale the technology across additional vehicles, locations and operations.